Dr. Shenghai Yuan

I received my B.S. and Ph.D. degrees in Electrical and Electronic Engineering from Nanyang Technological University, Singapore. My research focuses on robotics perception and navigation. Currently, I am a senior research fellow at the Centre for Advanced Robotics Technology Innovation (CARTIN) at Nanyang Technological University, Singapore. My research interest lies in robotics, with a focus on SLAM, sensor fusion, and autonomous navigation in challenging environments such as mines and dynamic human-robot spaces, aiming to advance adaptive and collaborative robotic systems.
I have authored or co-authored more than 200 peer-reviewed publications in robotics, computer vision, and AI, and contributed to more than 10 patents and other intellectual property outputs. I serve as an Associate Editor for Pattern Recognition, IEEE Transactions on Automation Science and Engineering (T-ASE), and Unmanned Systems, and as an Area Chair for RSS 2027 and a Senior Program Committee Member for AAAI 2027.
My service has been recognized with Outstanding Reviewer Awards from ICRA (2024), CVPR (2025), IEEE RA-L (2026), ECCV (2026), and NeurIPS (2026), and Best Associate Editor Awards from Unmanned Systems (2025 and 2026). Our work has also received the IROS 2023 Best Entertainment and Amusement Paper Award and the Best Poster Award at the ICRA 2026 Robot Meets Prior Map Workshop.
News
| Oct 20, 2026 | Named among the World’s Top 2% Scientists in 2026. |
|---|---|
| Oct 18, 2026 | Serving as an Area Chair for Robotics: Science and Systems (RSS) 2027. |
| Oct 16, 2026 | Received the NeurIPS 2026 Outstanding Reviewer Award. |
| Oct 09, 2026 | Invited talk at Singapore Institute of Technology on Reliable Robotic Systems: From Perception to Embodied Action. |
| Aug 10, 2026 | Received the ECCV 2026 Outstanding Reviewer Award. |
| Jul 15, 2026 | Received the 2026 Best Associate Editor Award from Unmanned Systems. |
| Jun 30, 2026 | 8 papers accepted to IROS 2026. IROS workshop Informative Path Planning also accepted. |
| Jun 25, 2026 | Serving as a Senior Program Committee Member for AAAI 2027. |
| Jun 04, 2026 | Received the Best Poster Award at the ICRA 2026 Robot Meets Prior Map Workshop. |
| Jun 03, 2026 | Received the IEEE Robotics and Automation Letters Outstanding Reviewer Award. |
| Apr 12, 2026 | Invited talk at Singapore Management University (SMU) on Towards Trustworthy Embodied AI. |
| Feb 23, 2026 | 2 papers accepted to CVPR 2026. IROS special session Robotics in Space Exploration accepted. |
| Jan 31, 2026 | 8 papers accepted to ICRA 2026. ICRA workshop Robot Meets Ranging also accepted. |
| Jan 23, 2026 | Invited talk at Guangdong University of Technology (GDUT) on LiDAR perception and learning-based state estimation for aerial and ground robots. |
| Jan 15, 2026 | 1 paper accepted to ICASSP 2026. |
Selected publications
Robot Design & Mechanisms
Datasets & Benchmarks
Counter-UAV Sensing & Control
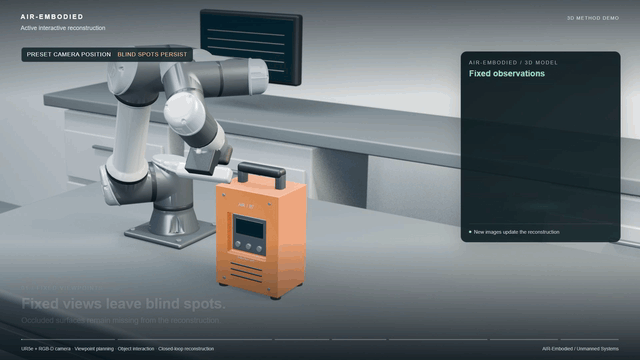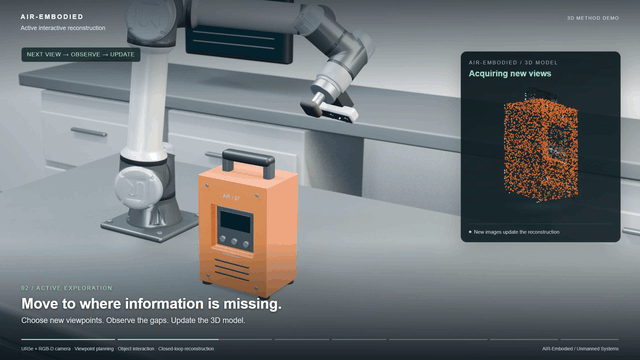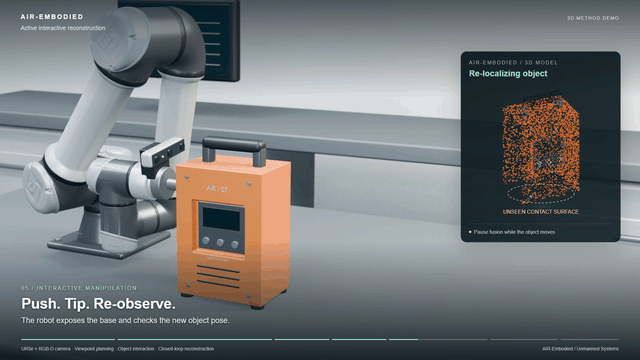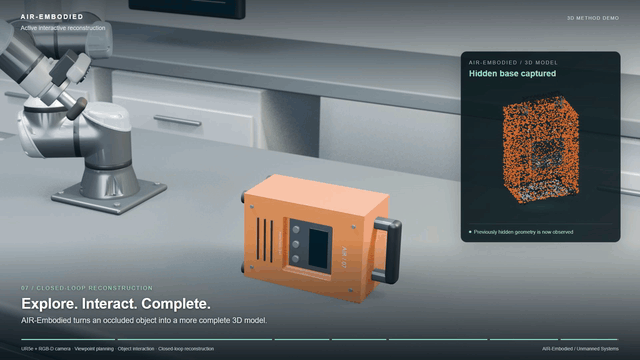
Embodied Intelligence & Interaction
- Review
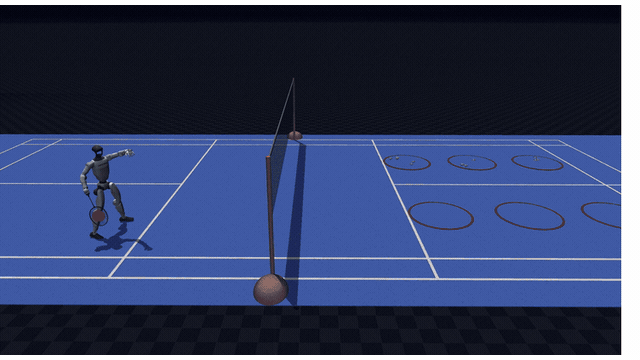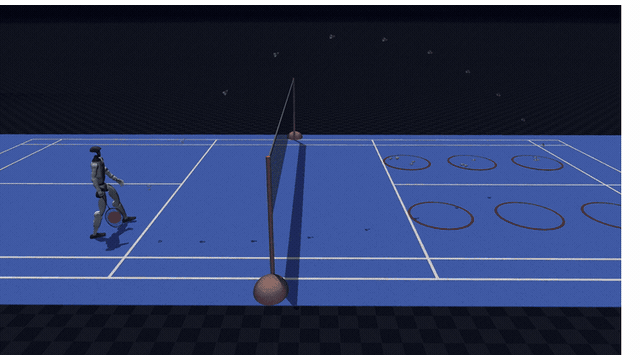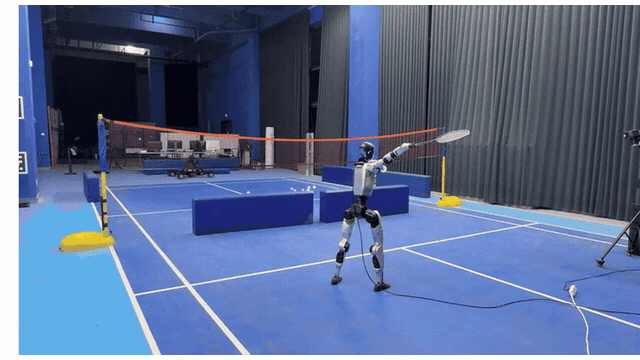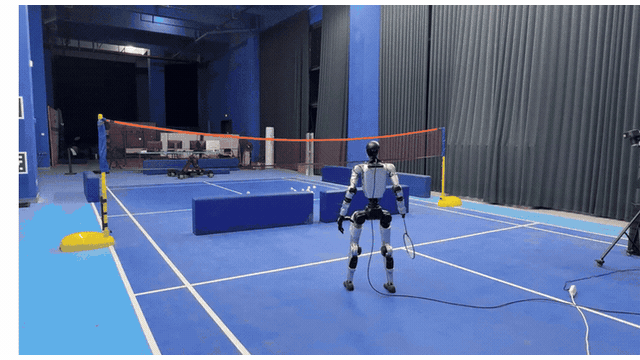 SERVE: Learning Agile Badminton Serving Skills Across Humanoid Embodiments2026Submitted for review
- Review
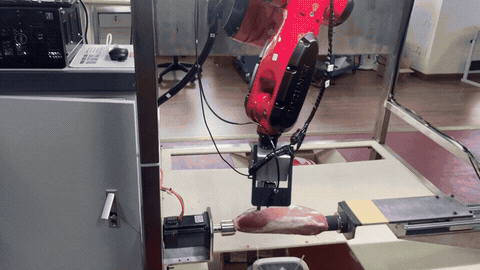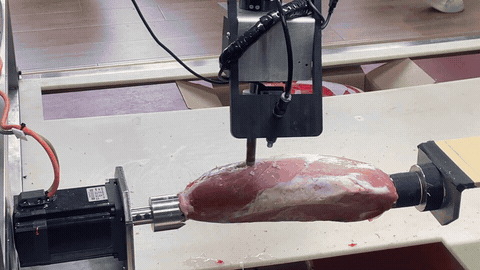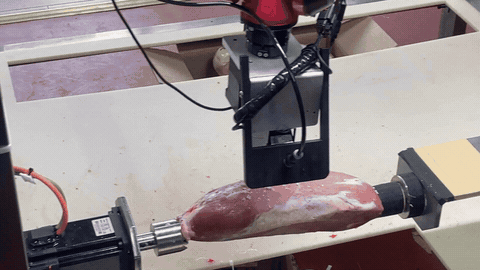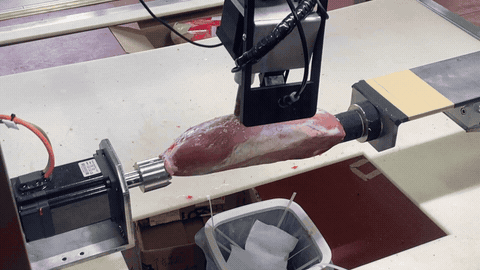 NexusBot: Geometry-Guided Perception and Manipulation of Irregular Biological Surfaces2026Submitted for review
Multimodal Perception & Mapping
UWB Localization & State Estimation
- ReviewCARE-UWB: Consistency-Aware Receding-Horizon Estimation for Large-Scale UWB-only Localization under Sparse and NLOS-Affected Radio Conditions2026Submitted for review
- ReviewPolicy-Guided Trust Allocation for Single-Anchor UWB-Aided Neural Inertial Odometry2026Submitted for review
- ReviewSingle-Anchor-UWB Aided Neural-Inertial Odometry with Adaptive-Horizon Model Predictive Path Integral Fusion2026Submitted for review
- ReviewMAUFormer: A Map-Aware UWB Transformer for Large-Scale Localization with Few-Shot Trajectory Priors2026Submitted for review
- ReviewFSULoc: Few-Shot UWB Localization with Sparse Anchors in Large-Scale NLOS Environments2026Submitted for review
Field & Assistive Robotics
Visitors around the world
Visitor statistics