Publications
Publications grouped by conference and ordered by conference or journal publication date, newest first.
* denotes corresponding author; † denotes equal contribution where indicated in the publication.
Manuscripts
- ReviewCARE-UWB: Consistency-Aware Receding-Horizon Estimation for Large-Scale UWB-only Localization under Sparse and NLOS-Affected Radio Conditions2026Submitted for review
- Review
- ReviewFSULoc: Few-Shot UWB Localization with Sparse Anchors in Large-Scale NLOS Environments2026Submitted for review
- ReviewMAUFormer: A Map-Aware UWB Transformer for Large-Scale Localization with Few-Shot Trajectory Priors2026Submitted for review
- Review
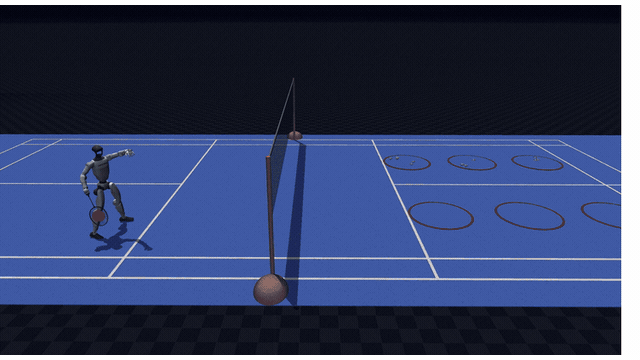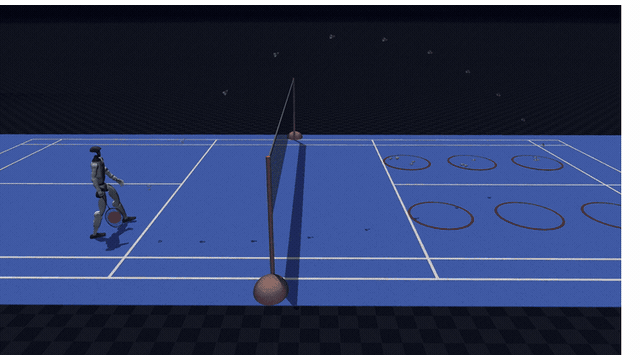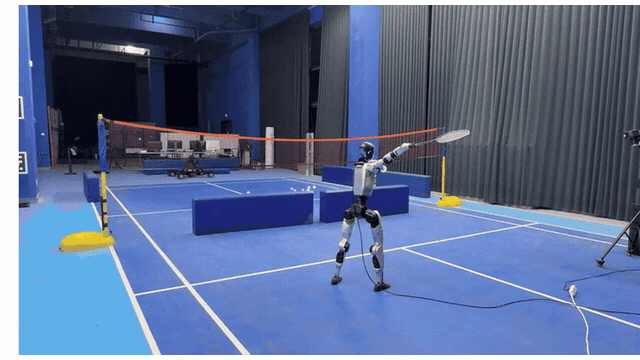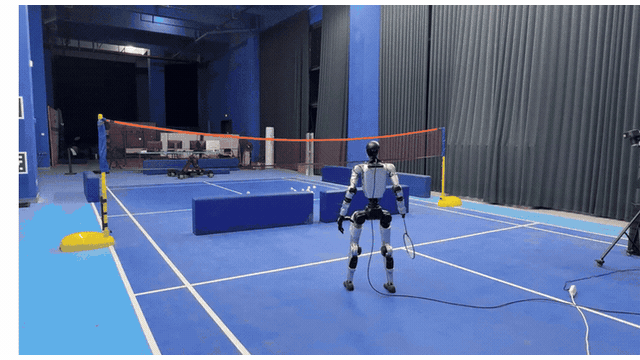 SERVE: Learning Agile Badminton Serving Skills Across Humanoid Embodiments2026Submitted for review
- Review
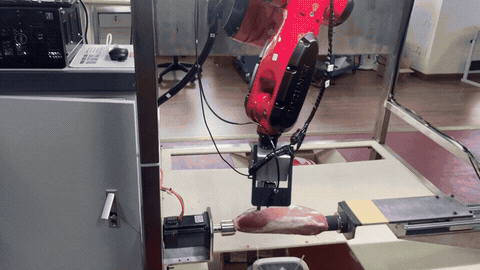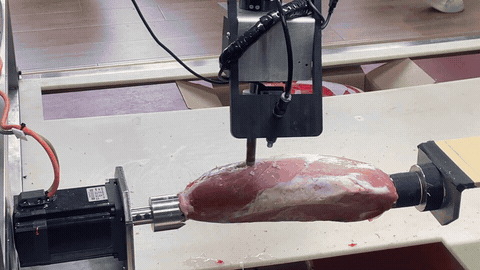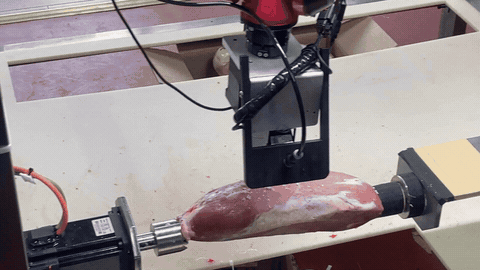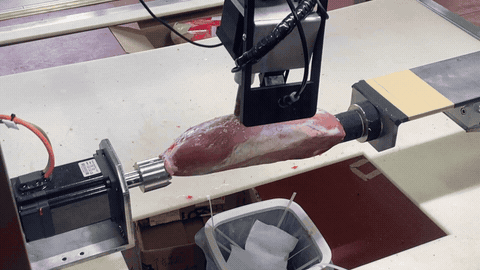 NexusBot: Geometry-Guided Perception and Manipulation of Irregular Biological Surfaces2026Submitted for review
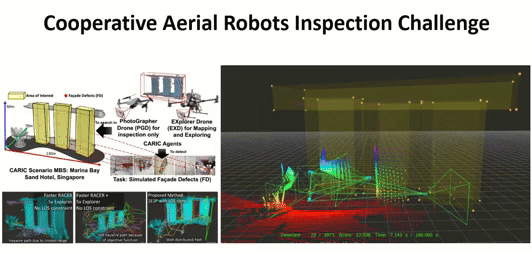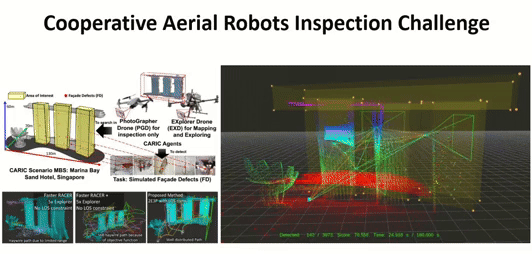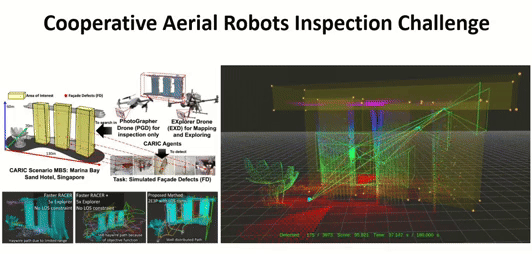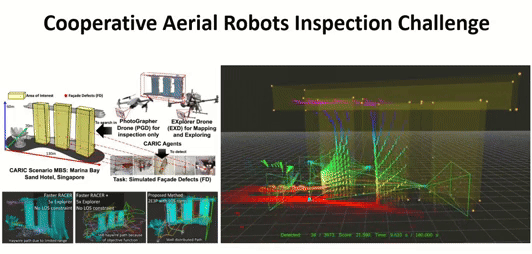
- ReviewSPQR: Structural-Prior-Guided Pathwise Querying and Routing for Multi-UAV Exploration2026Submitted for review
- Manuscript
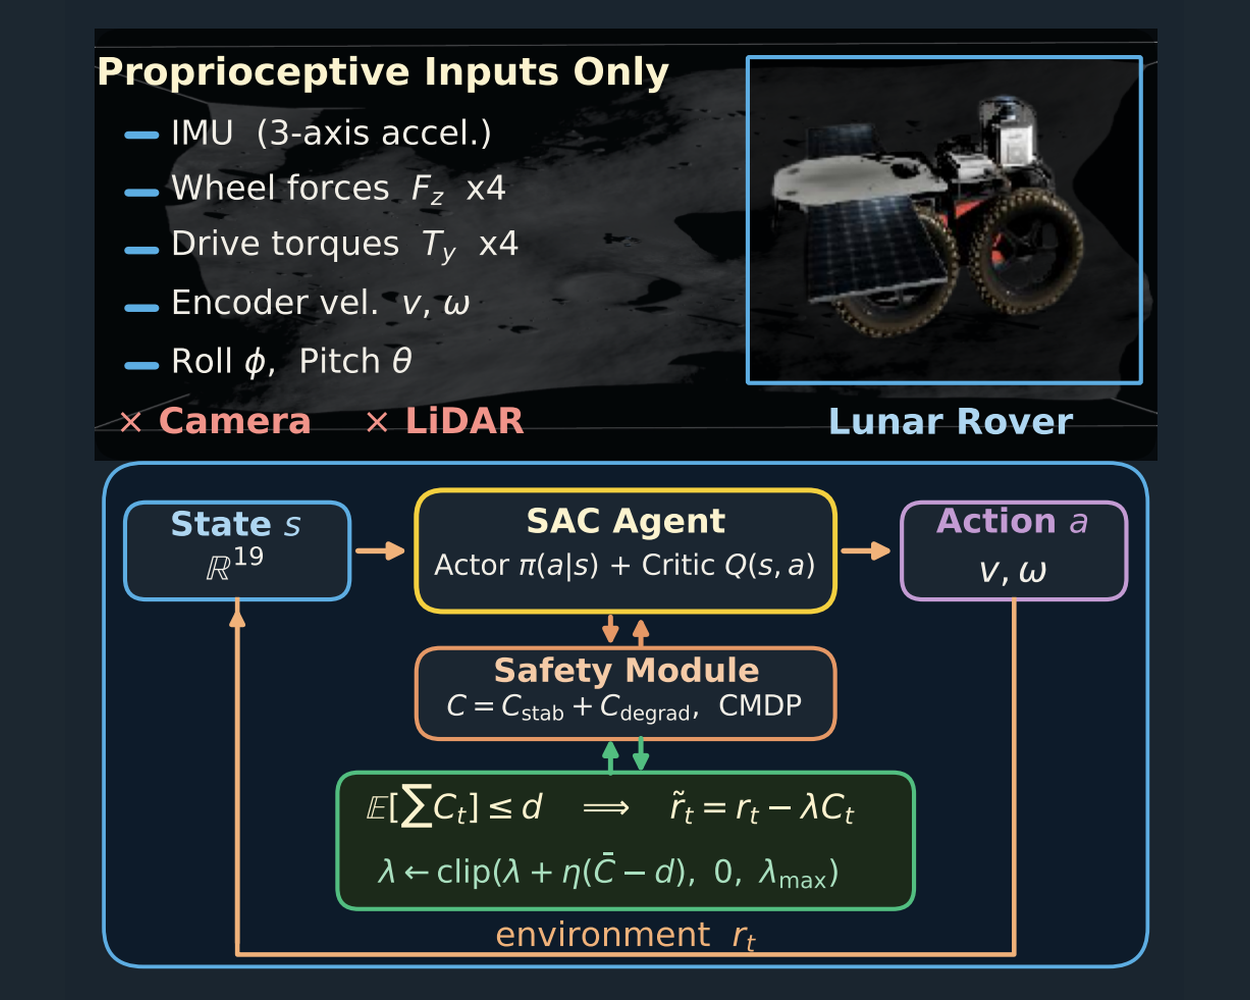
- Manuscript
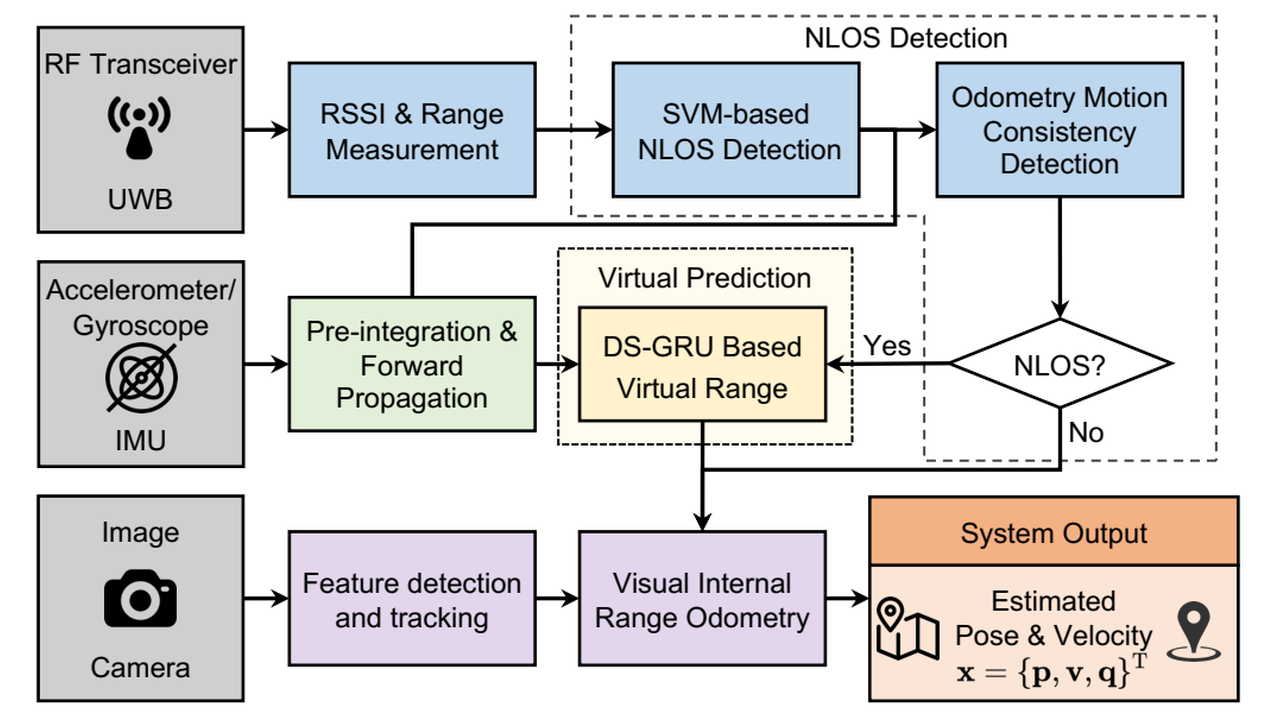 NLOS-Aware Multi-Robot Visual–Inertial–Ranging Localization with Virtual Ranging Compensation2026
- Manuscript
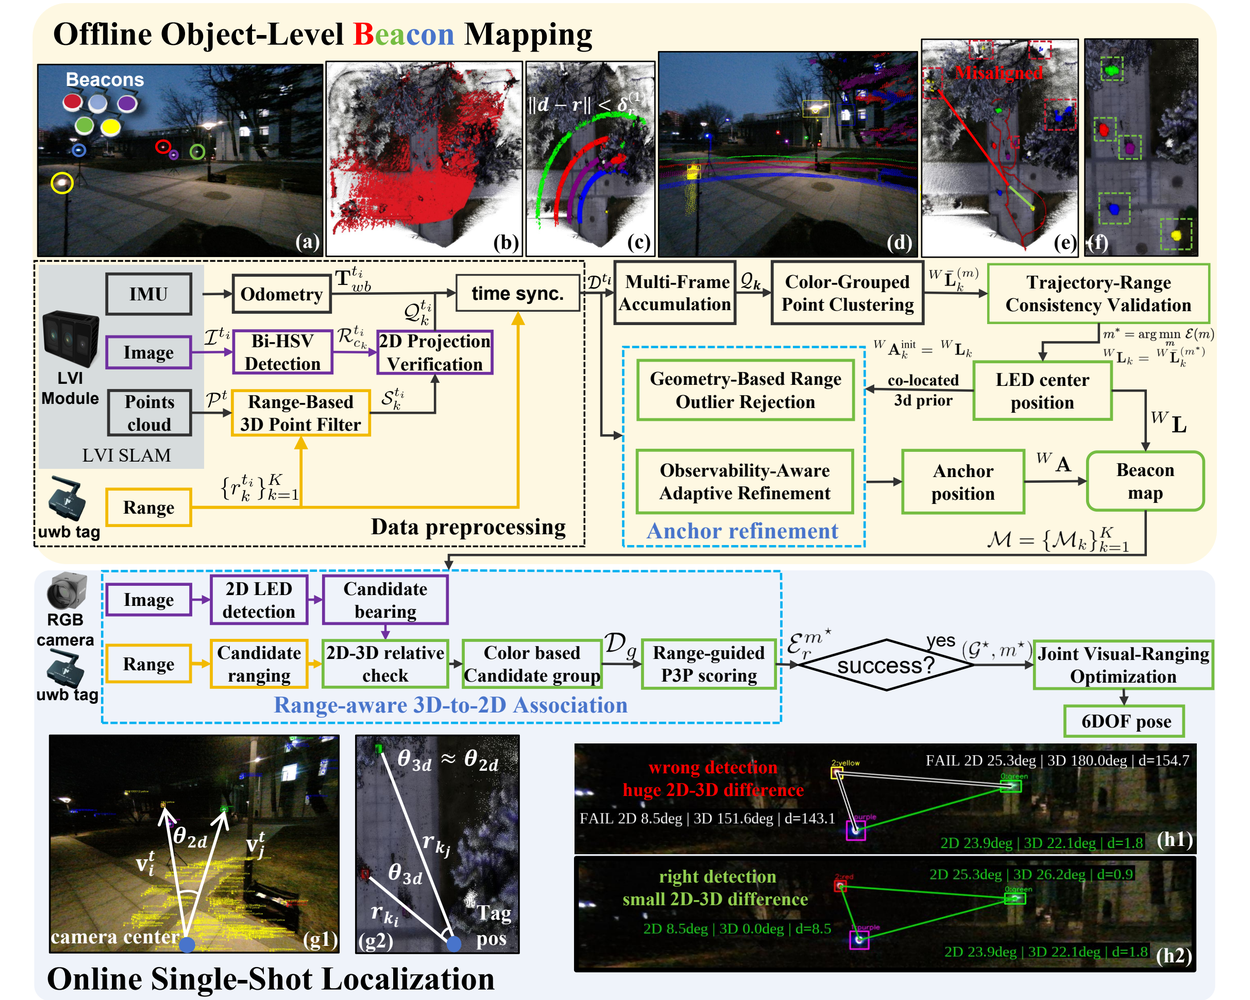 Night Beacon: Co-Located LED-UWB Beacon Calibration and One-Shot Localization for Nocturnal Navigation2026
- ReviewAGMarker-SLAM: A Marker-Assisted Aerial-Ground Collaborative SLAM System for Robust Map Fusion2026Submitted for review
- Review
- ReviewSemantic-Geometric Prior Reasoning for Elevator Panel Layout Recovery under Partial and Noisy Observation2026Submitted for review
- ReviewSingle-Anchor-UWB Aided Neural-Inertial Odometry with Adaptive-Horizon Model Predictive Path Integral Fusion2026Submitted for review
- Review
- ReviewMCULoc: Motion-Consistent UWB Localization under Sparse Ranging with Few-Shot Trajectory Priors2026Submitted for review
- ReviewLCALoc: Learning Covariance Adaptation for Few-Shot UWB Localization with Sparse Ranges in Large-Scale Environments2026Submitted for review
- ReviewConnectivity-Aware Reinforcement Learning for Multi-Agent Exploration under Constrained Field of View2026Submitted for review
- ReviewPolicy-Guided Trust Allocation for Single-Anchor UWB-Aided Neural Inertial Odometry2026Submitted for review
Publications and preprints
2027
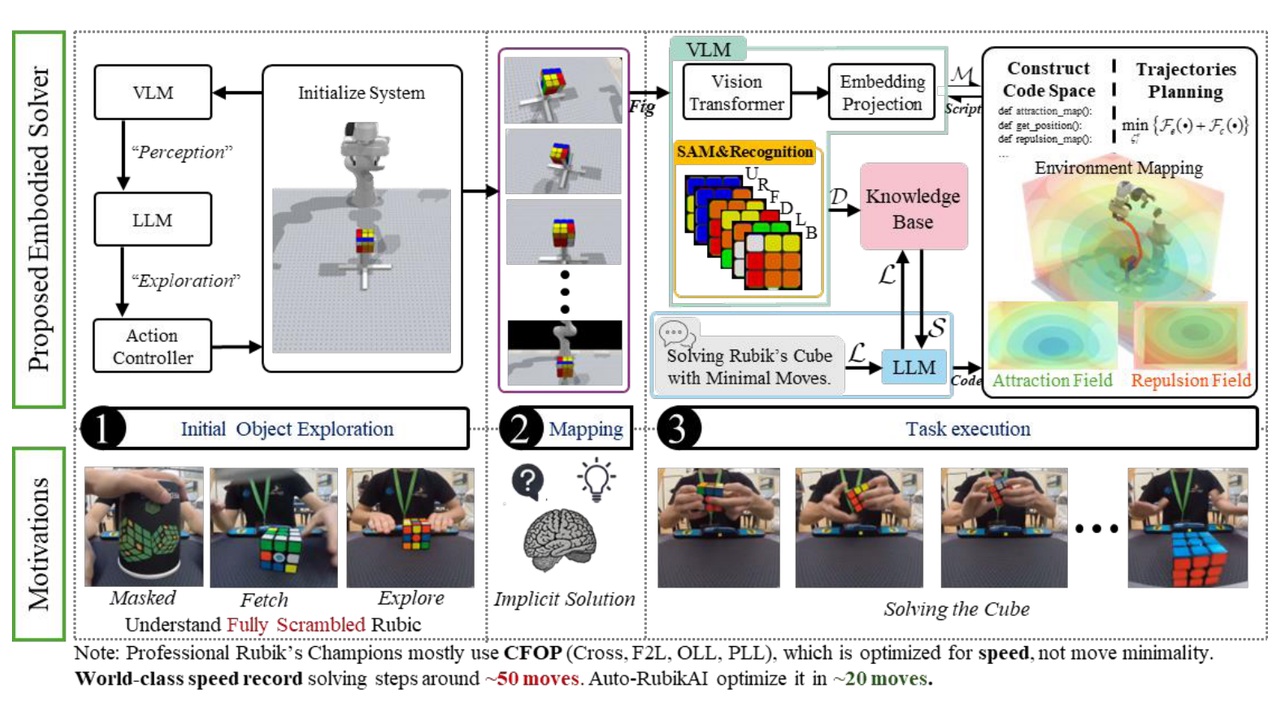
2026
- ICARCV
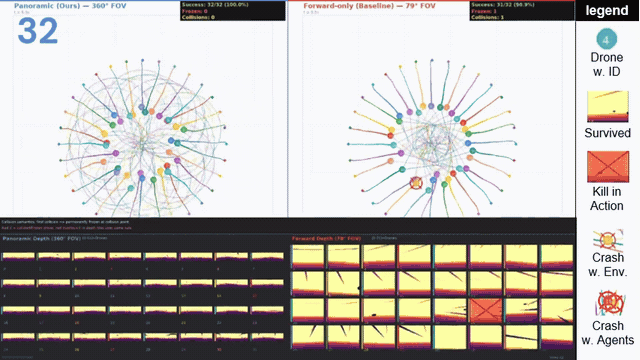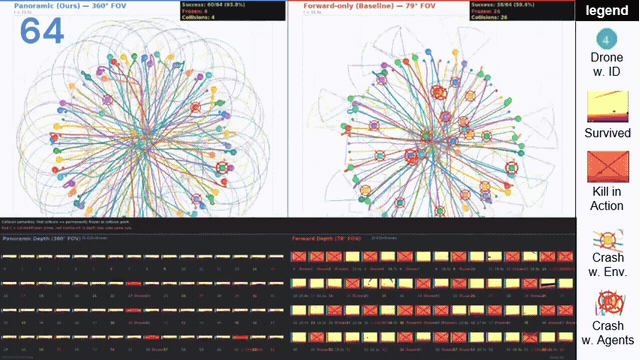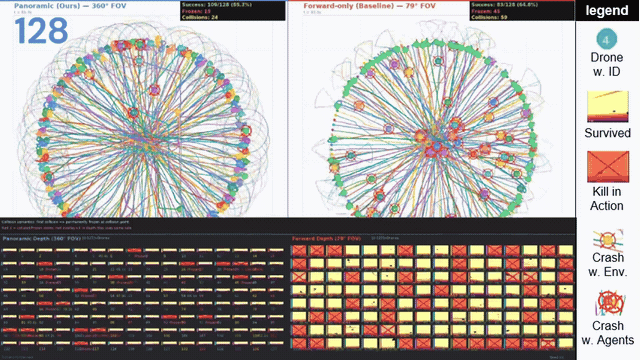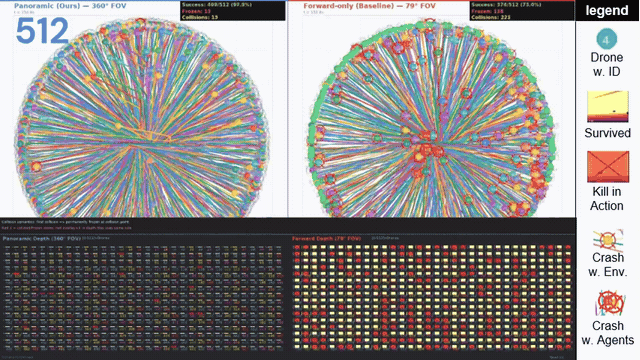
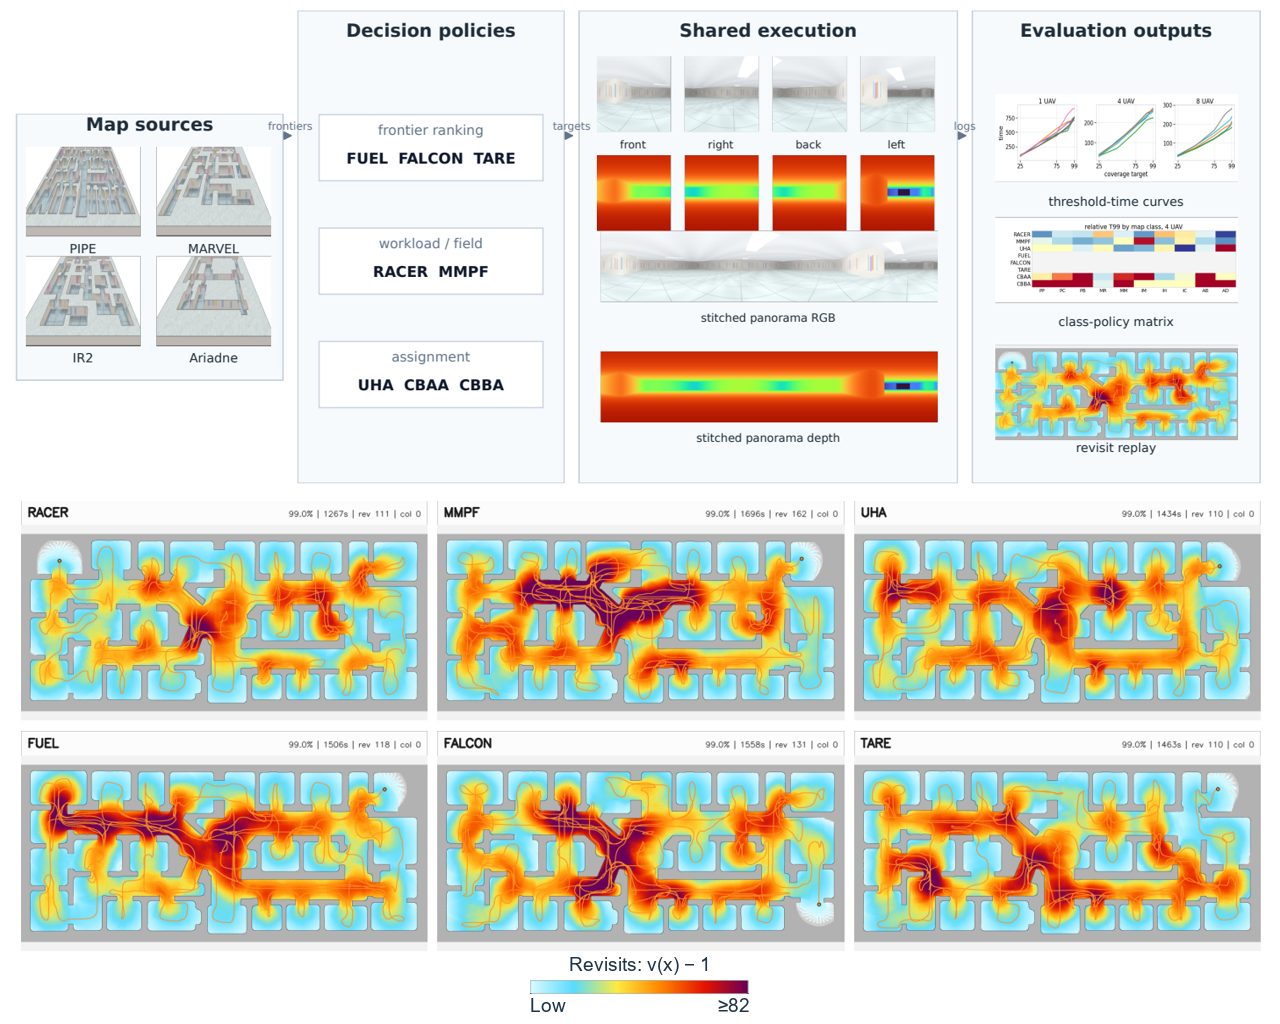 FLEX: A Benchmark for Indoor UAV Exploration PoliciesIn 19th International Conference on Control, Automation, Robotics and Vision (ICARCV), 2026
-
- Modeling Multi-Segment Acceleration for Event Camera Rotation EstimationPattern Recognition, 2026
- IoT-J
- T-Mech
- ICCA
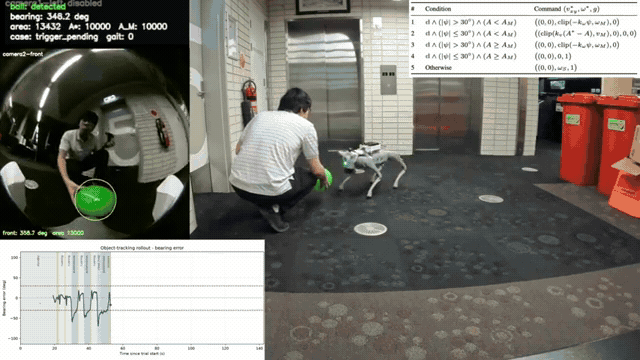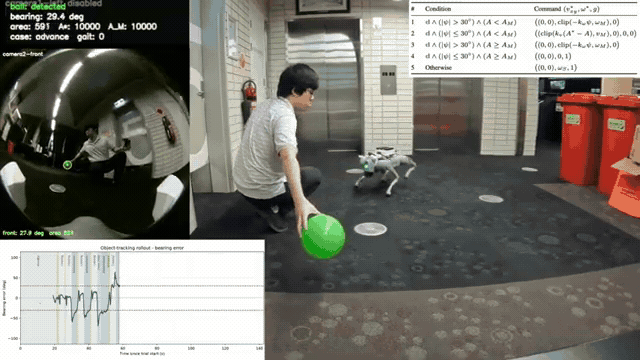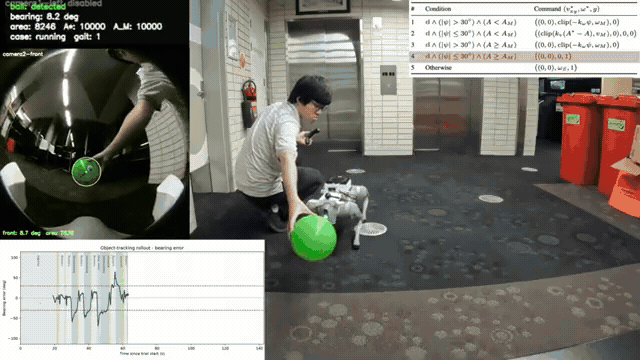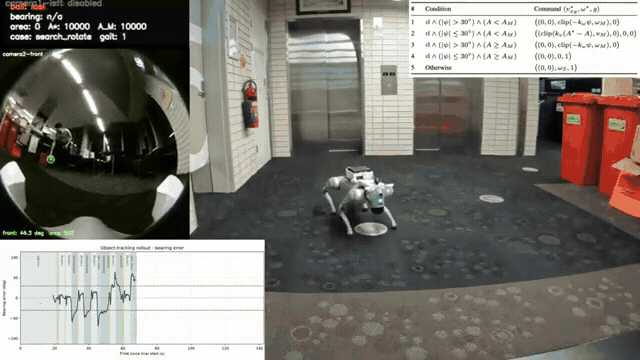
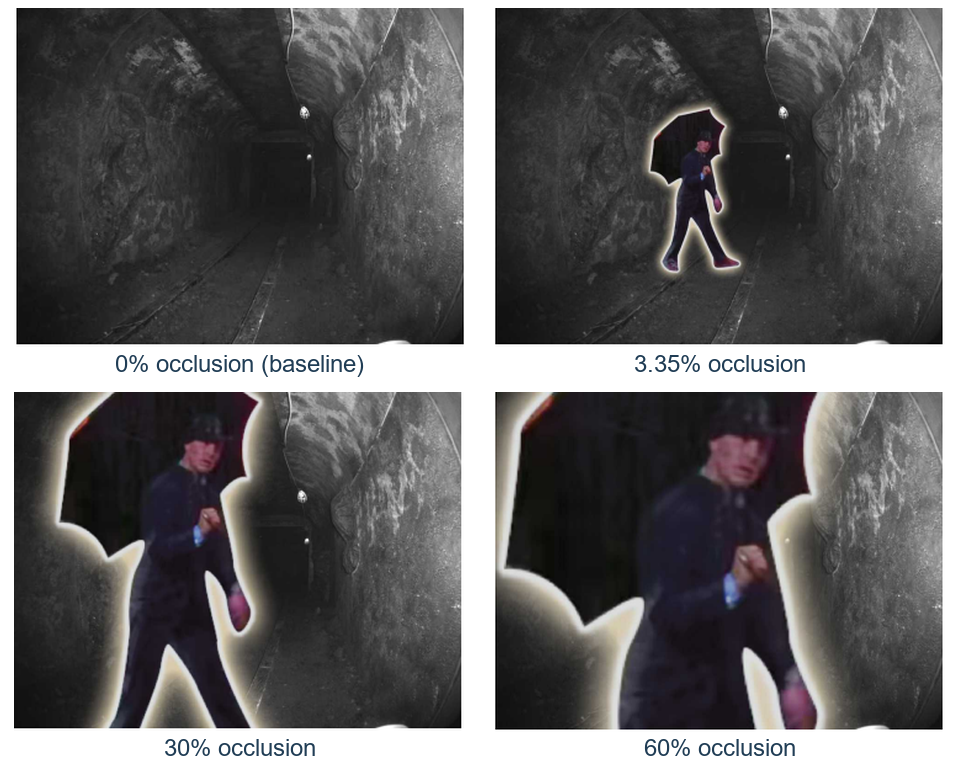
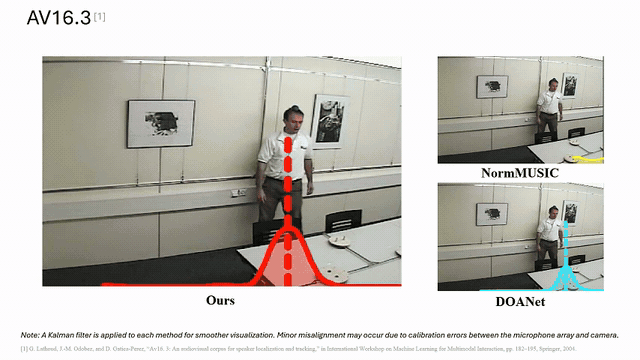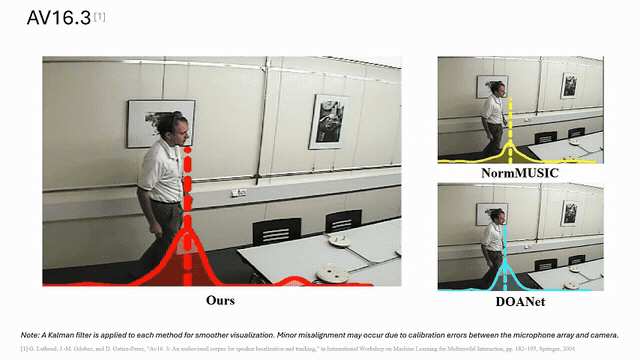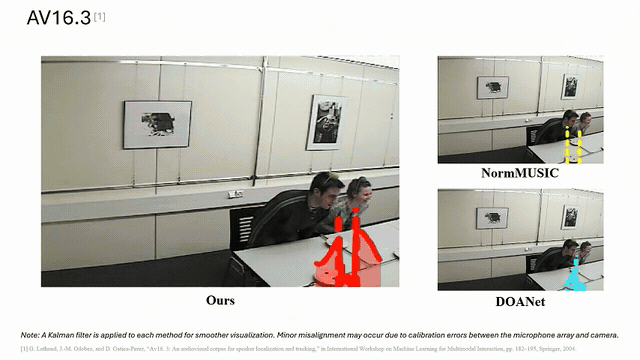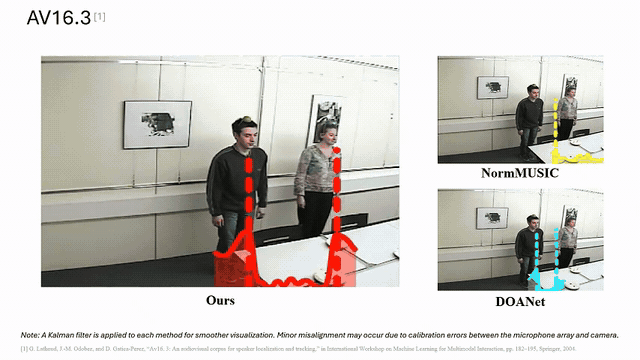
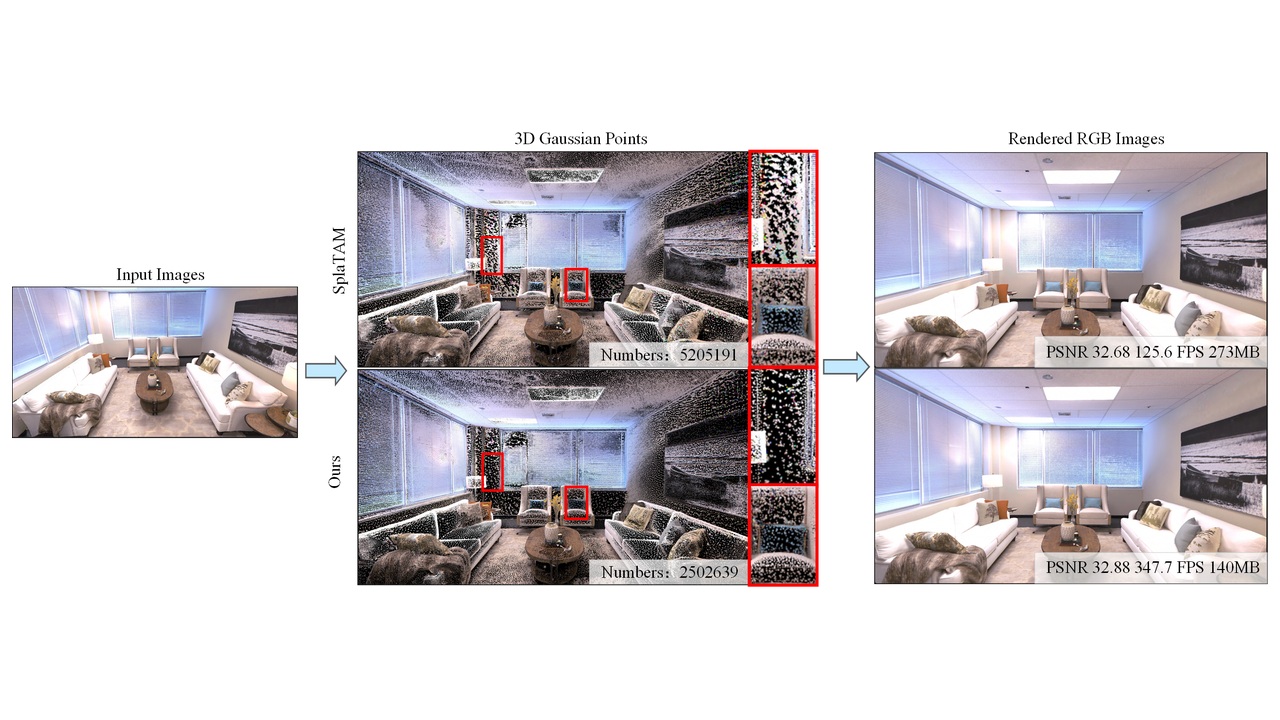
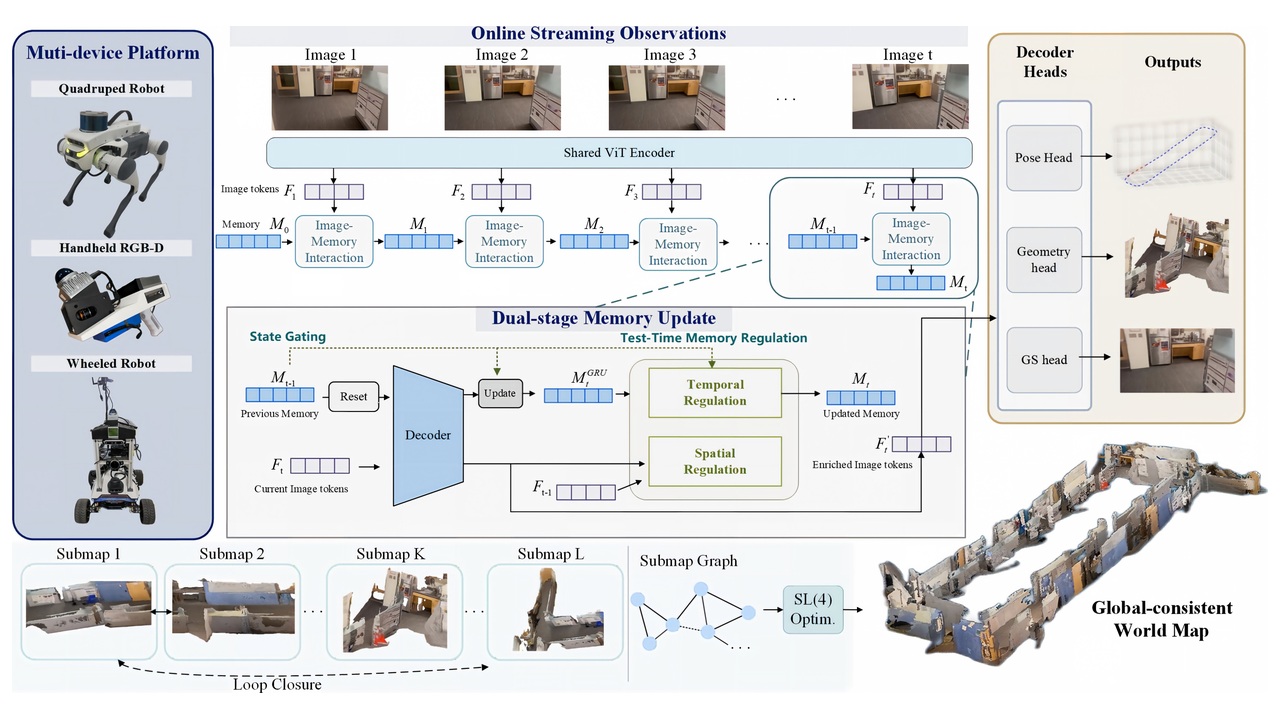

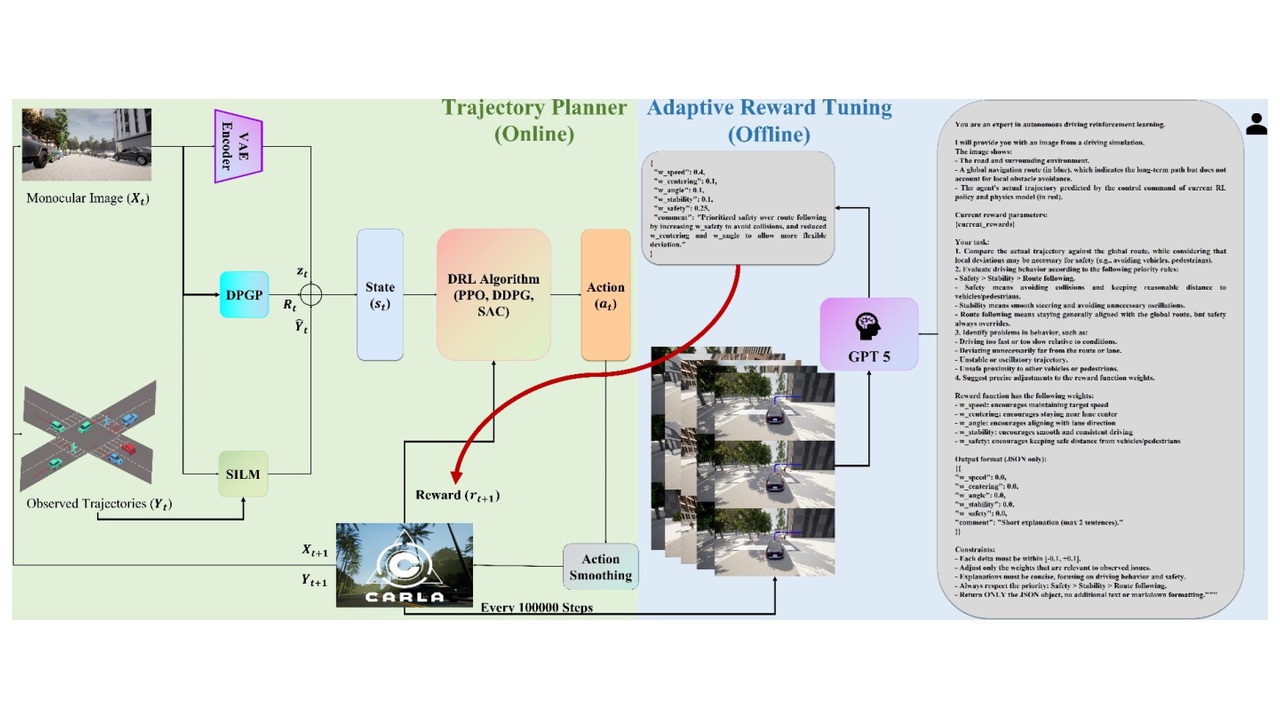
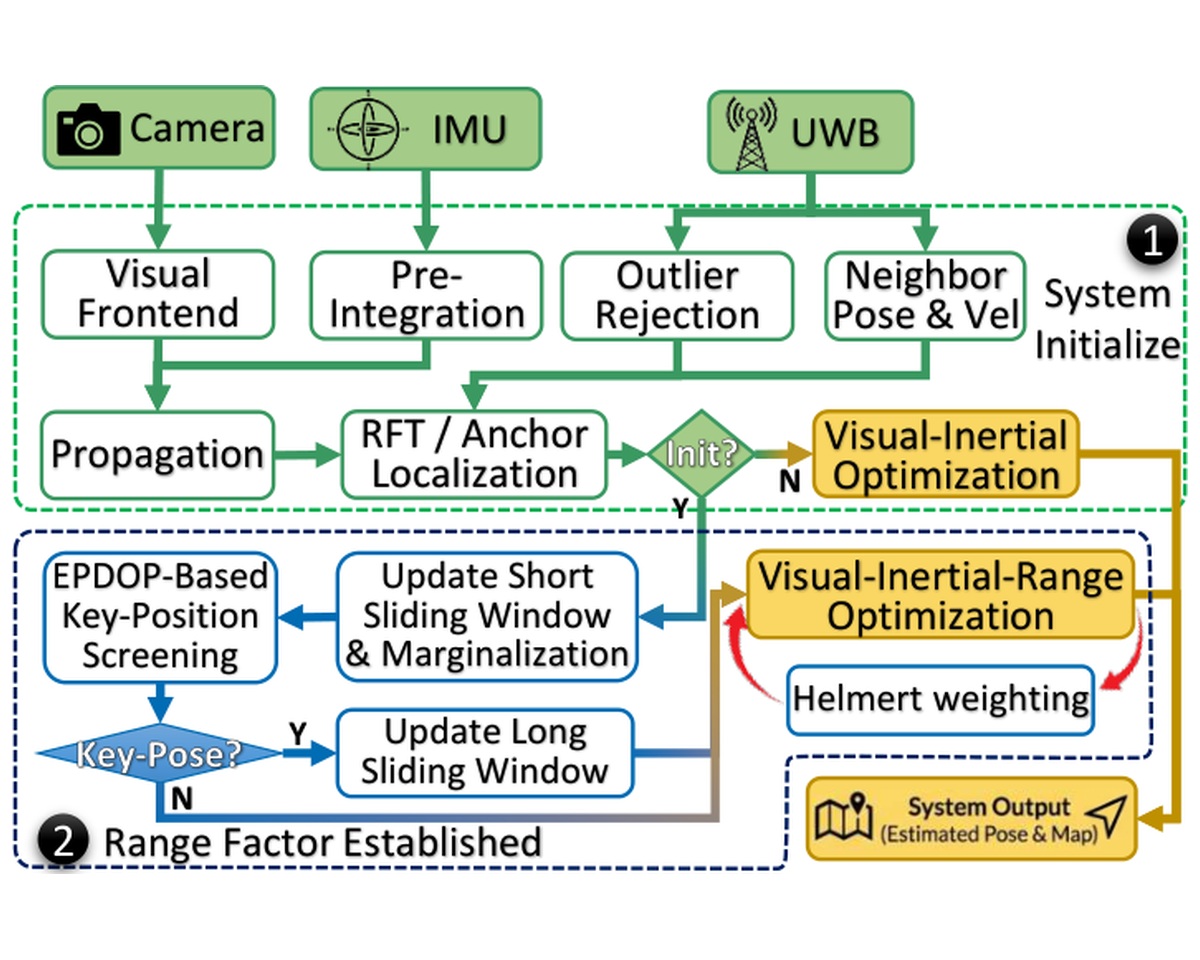
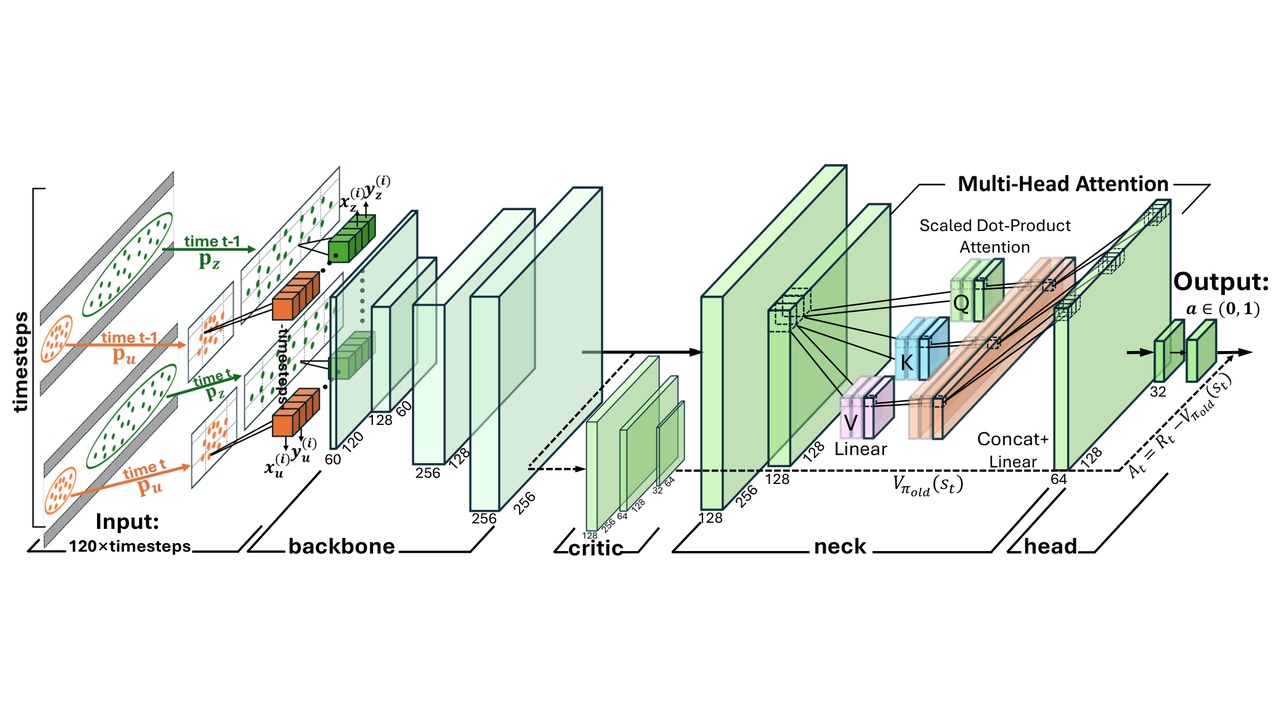
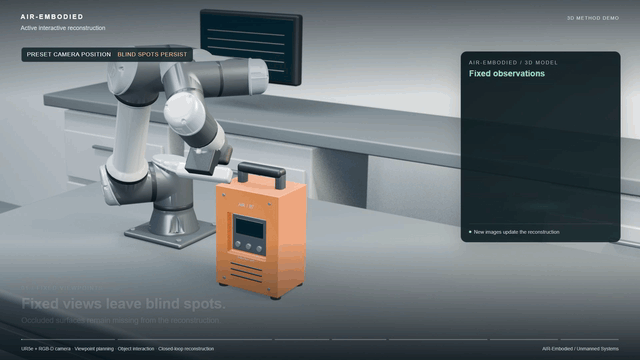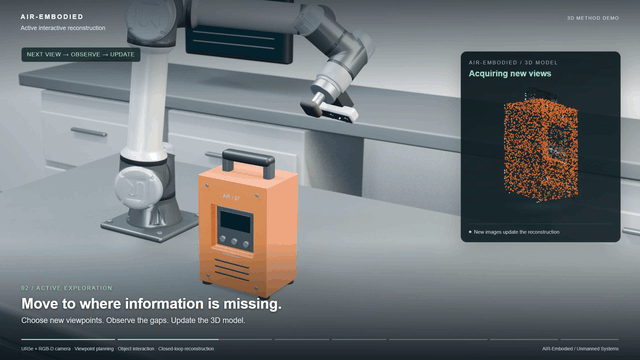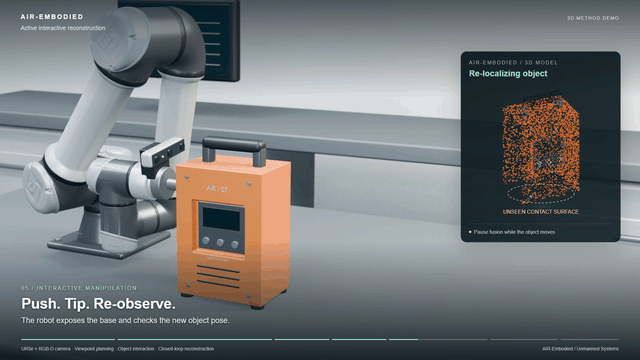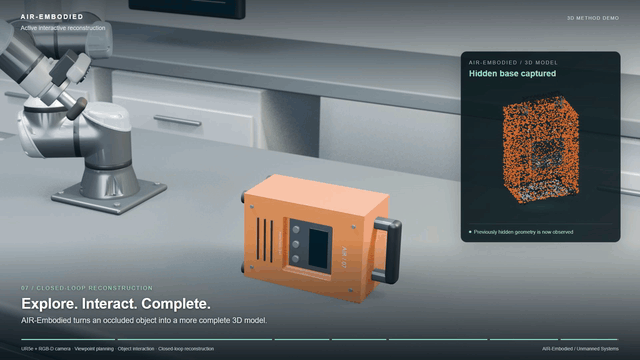
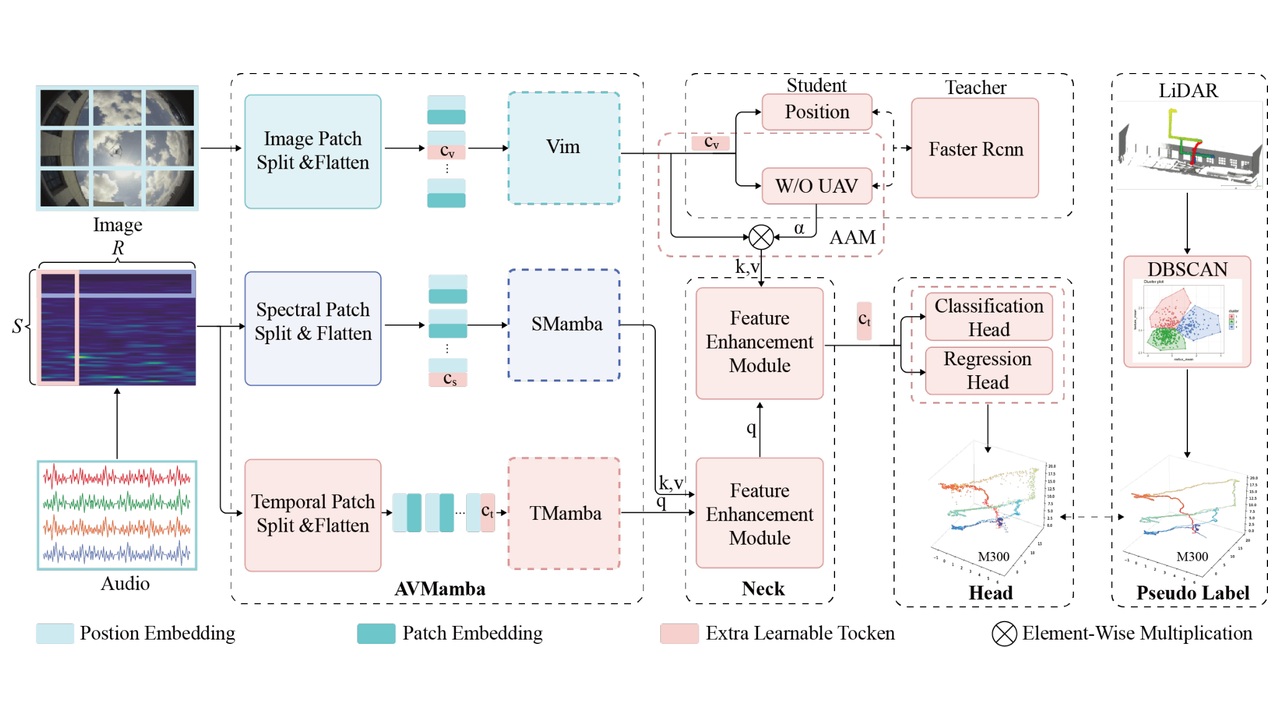
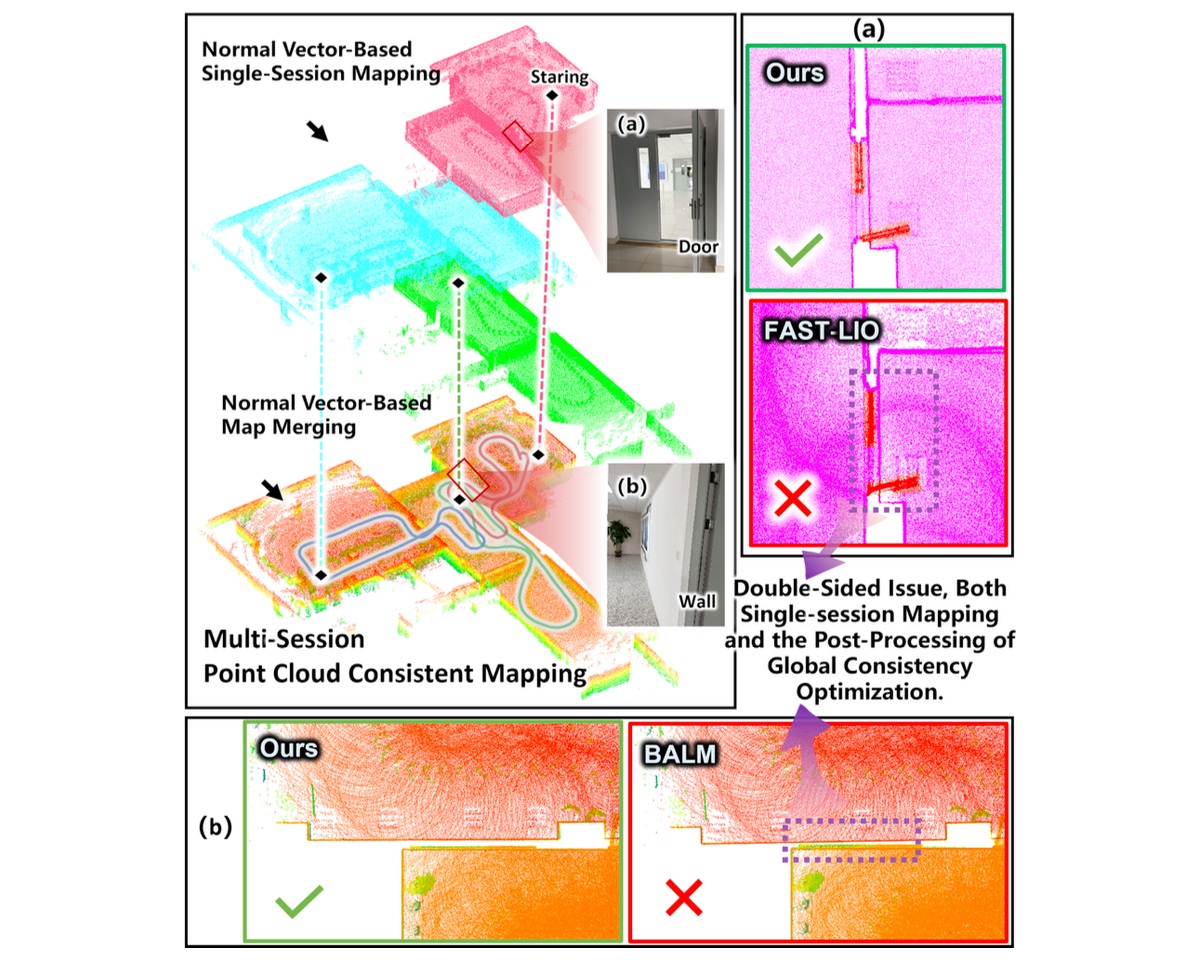
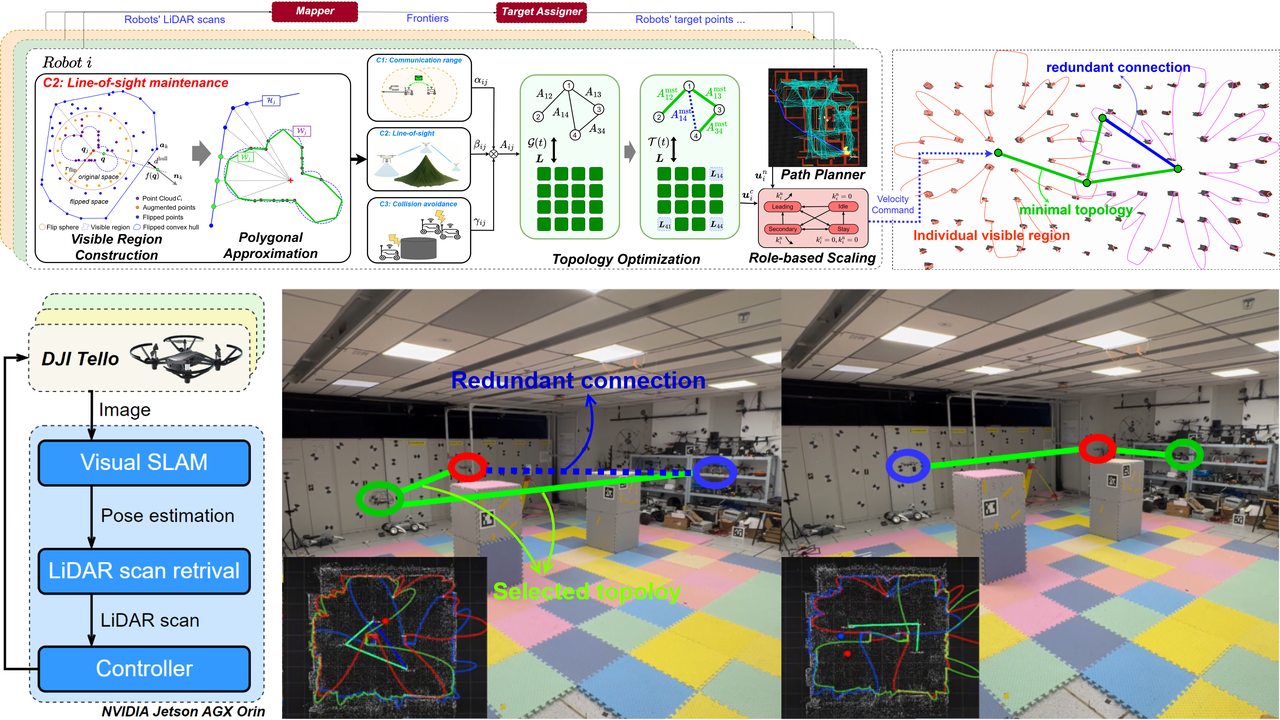
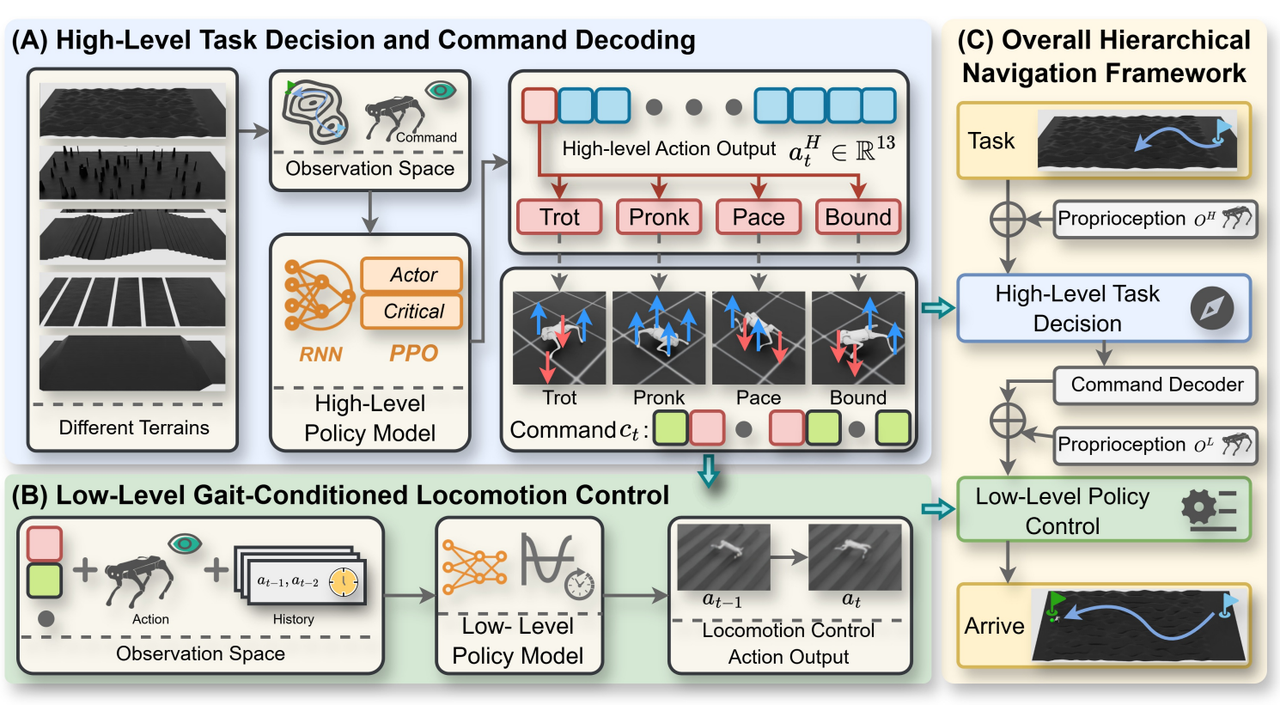
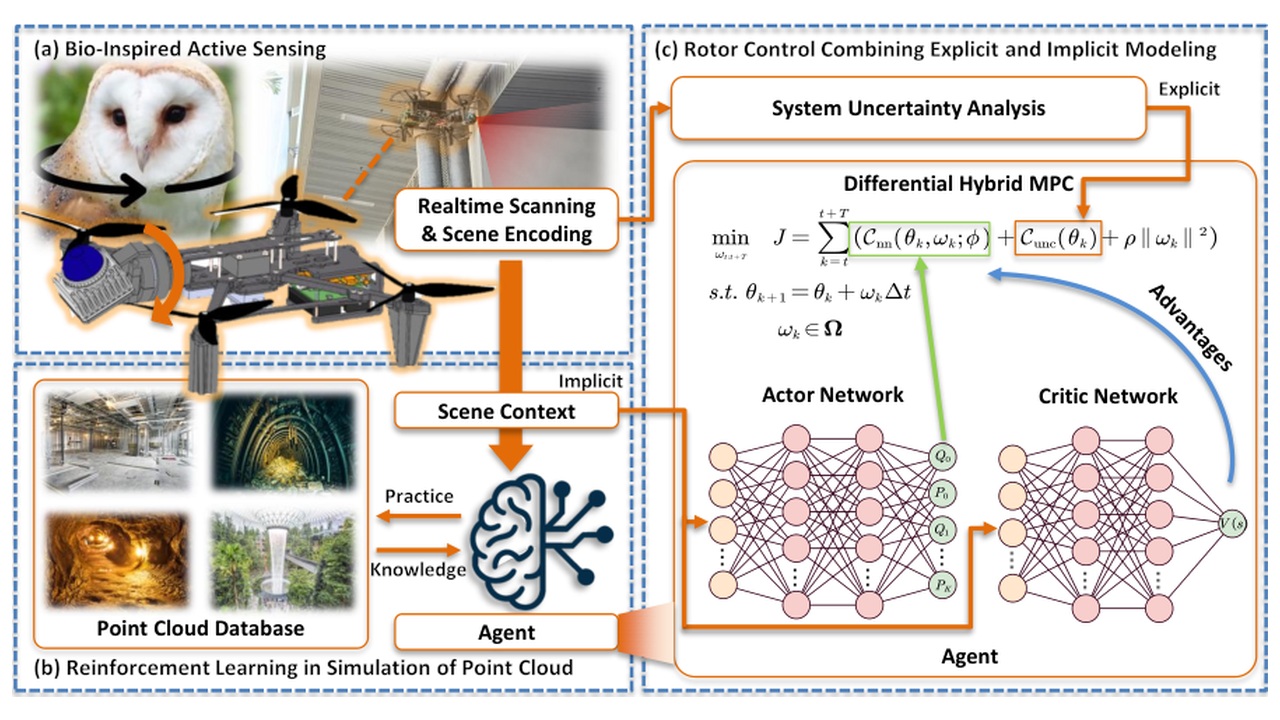
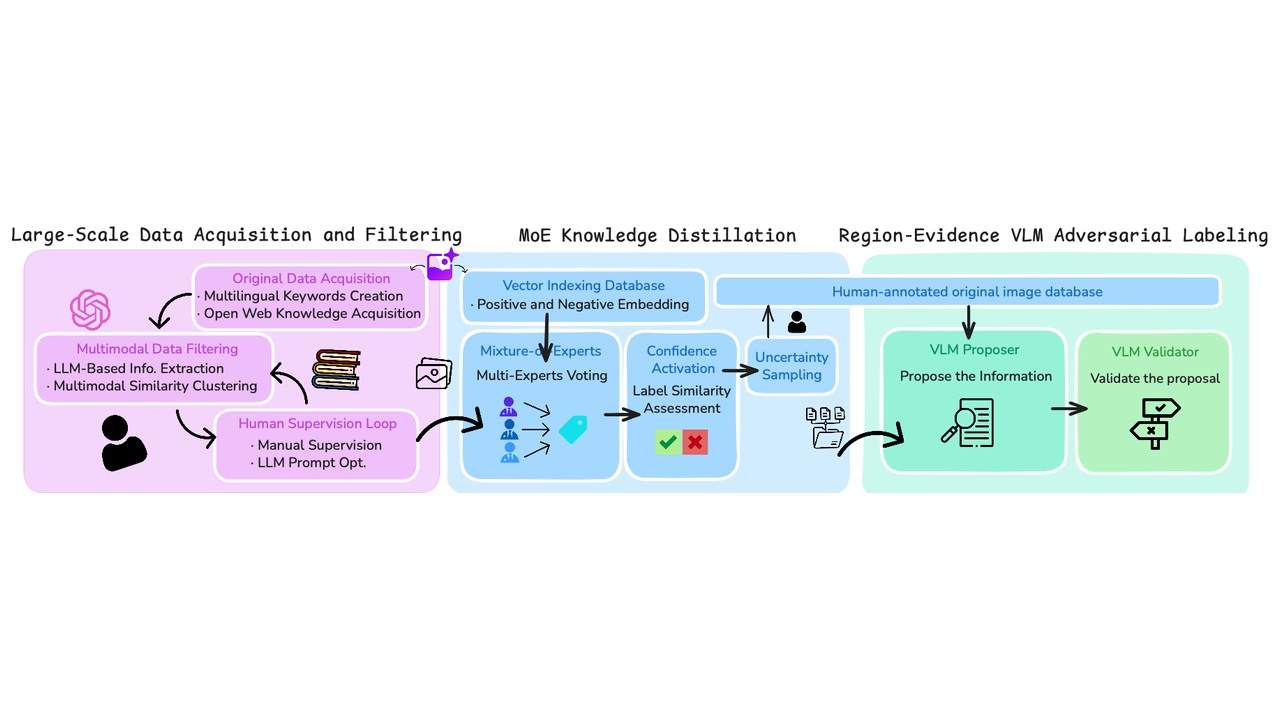
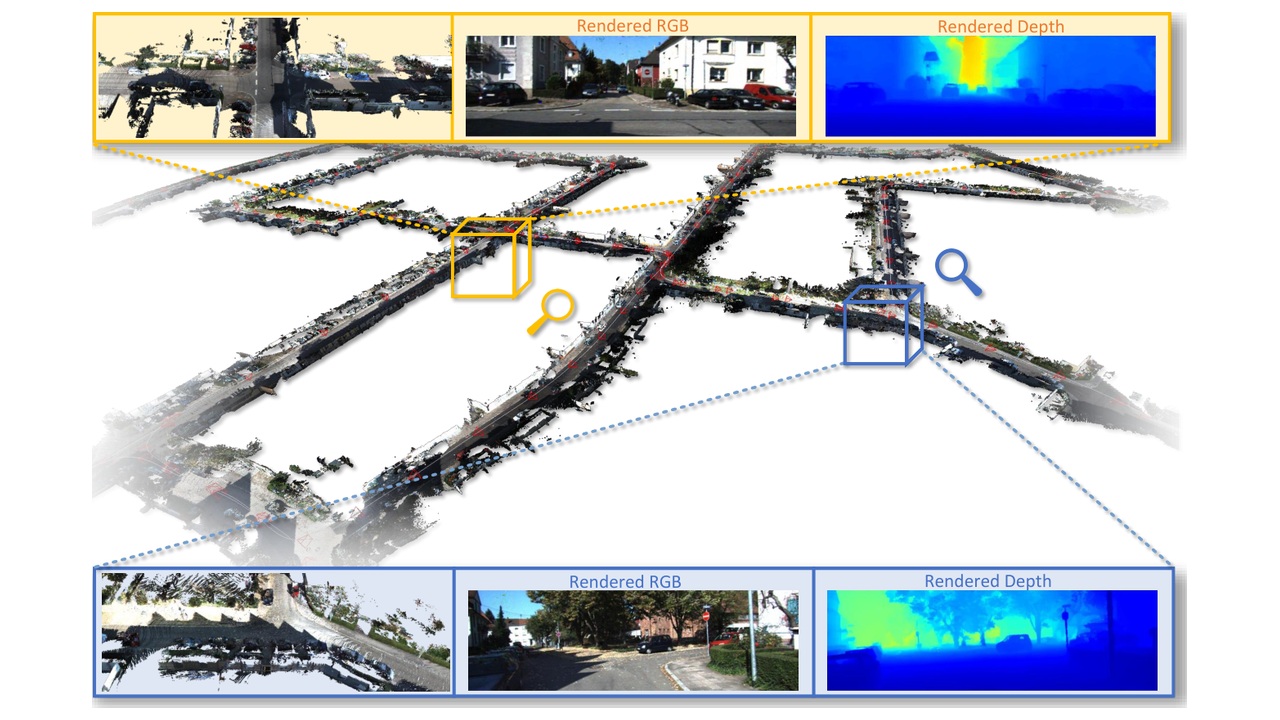
2025
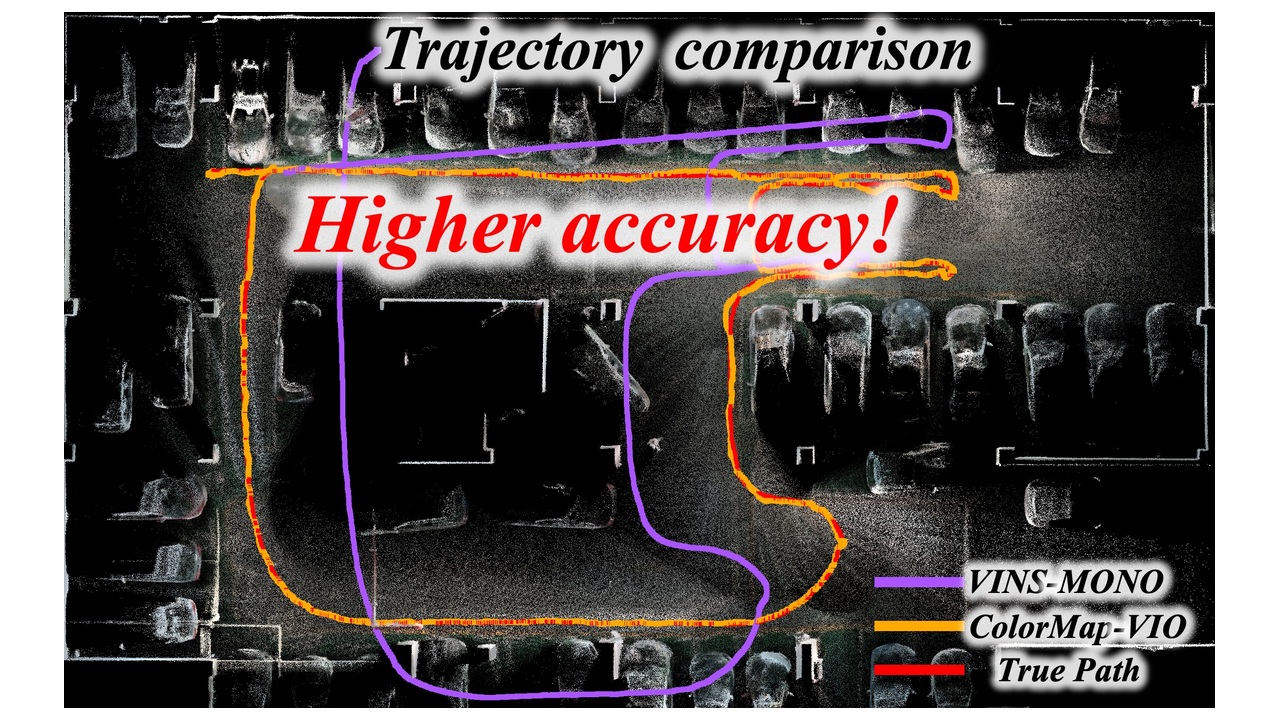
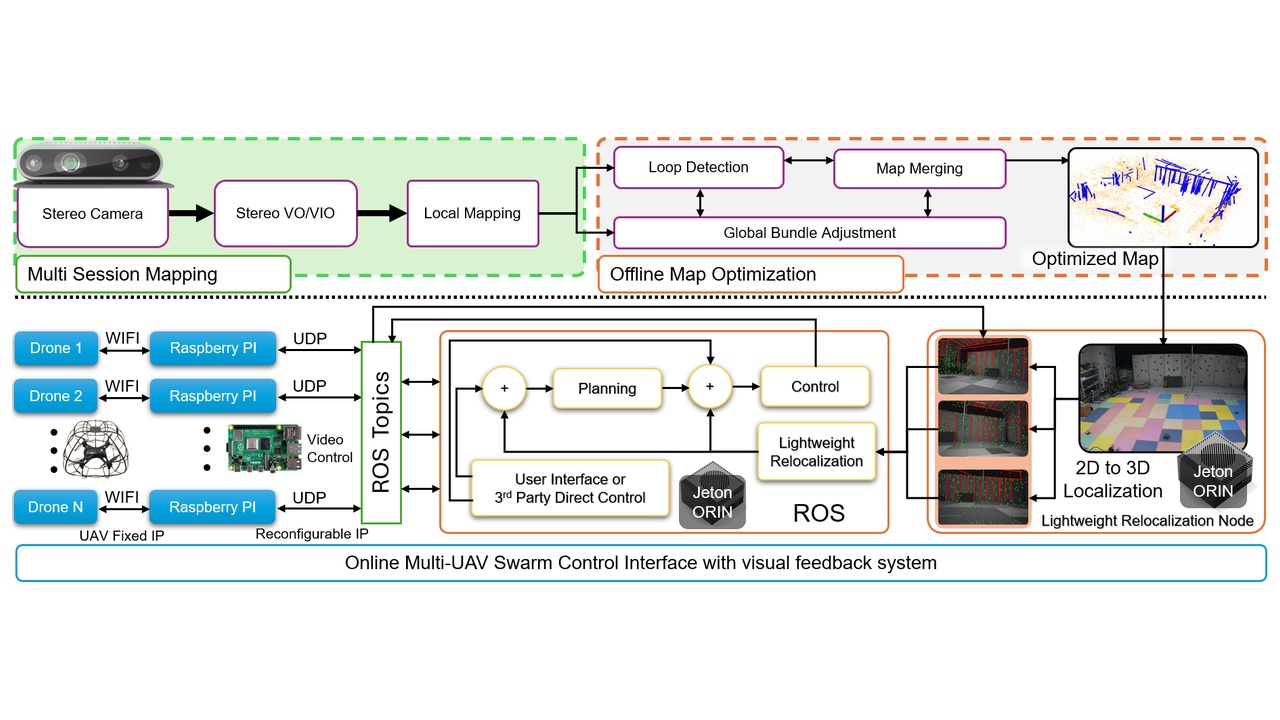
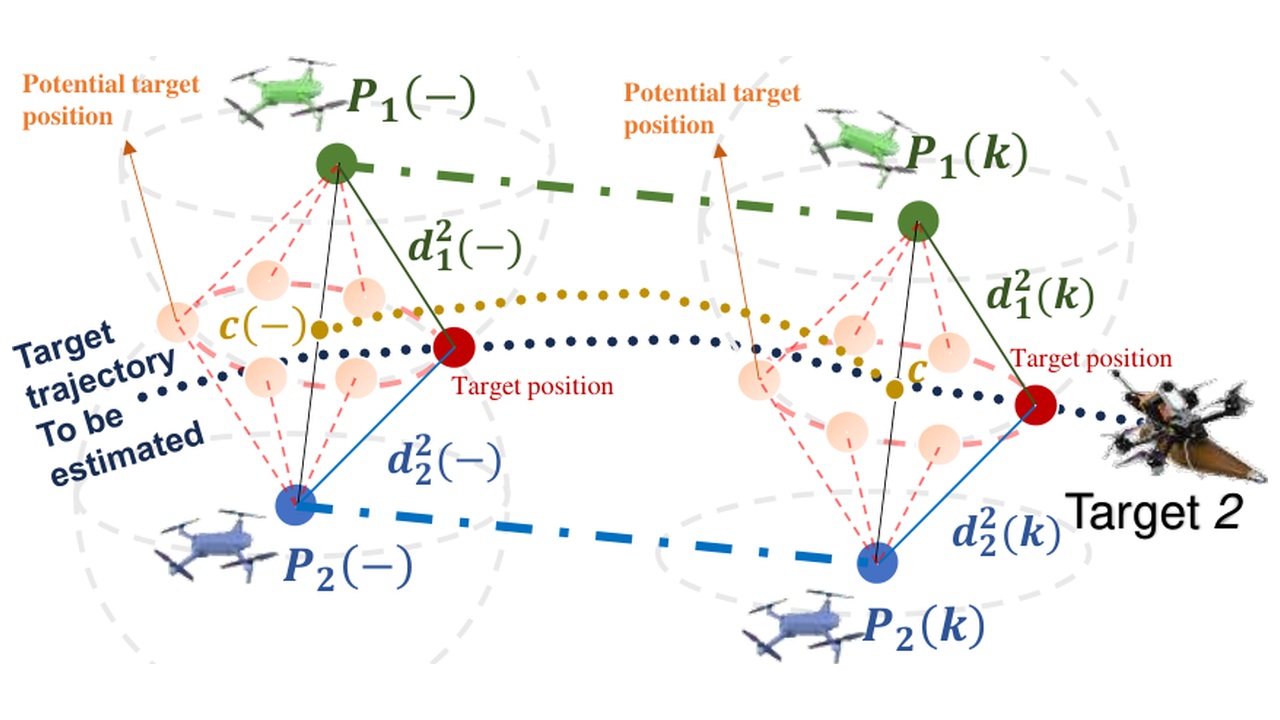

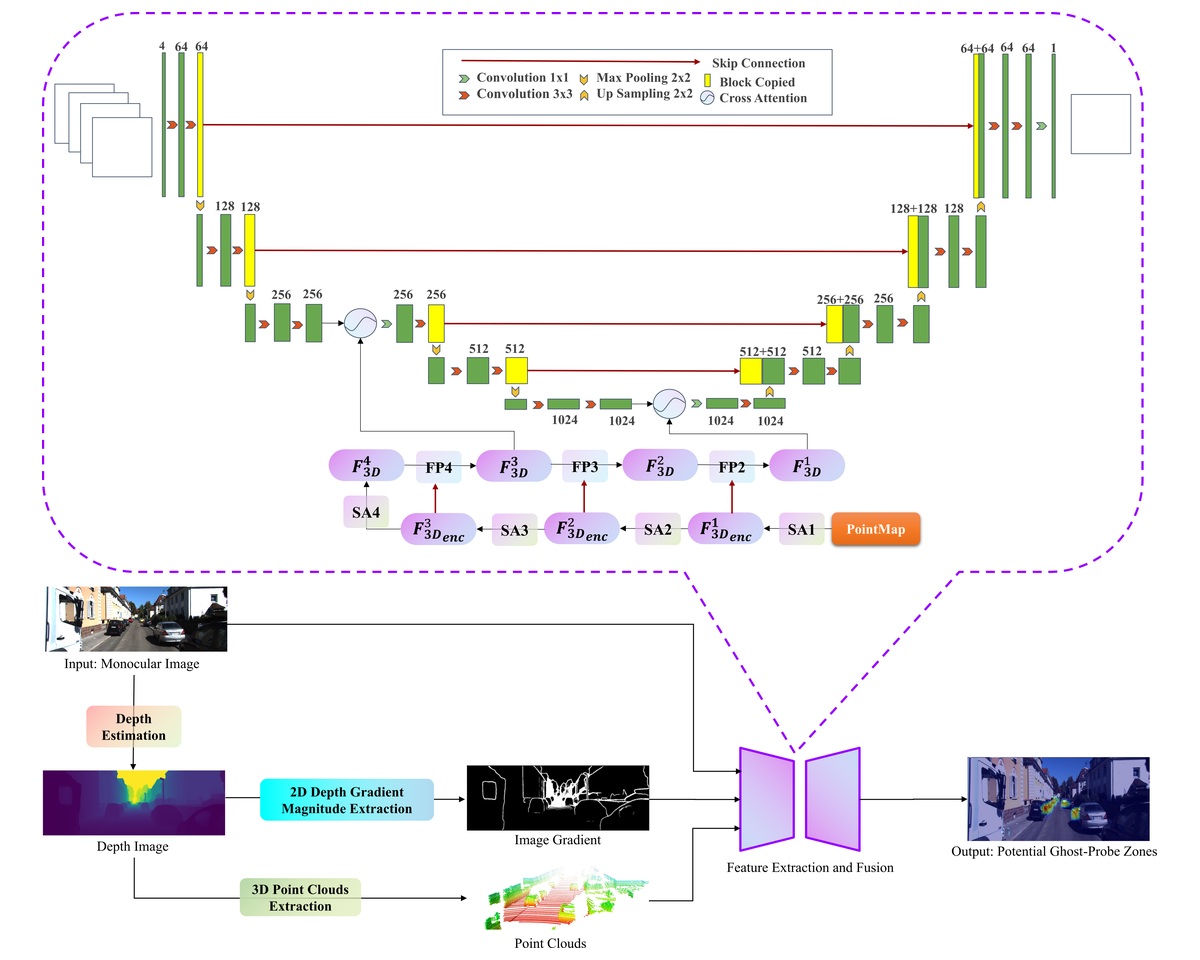
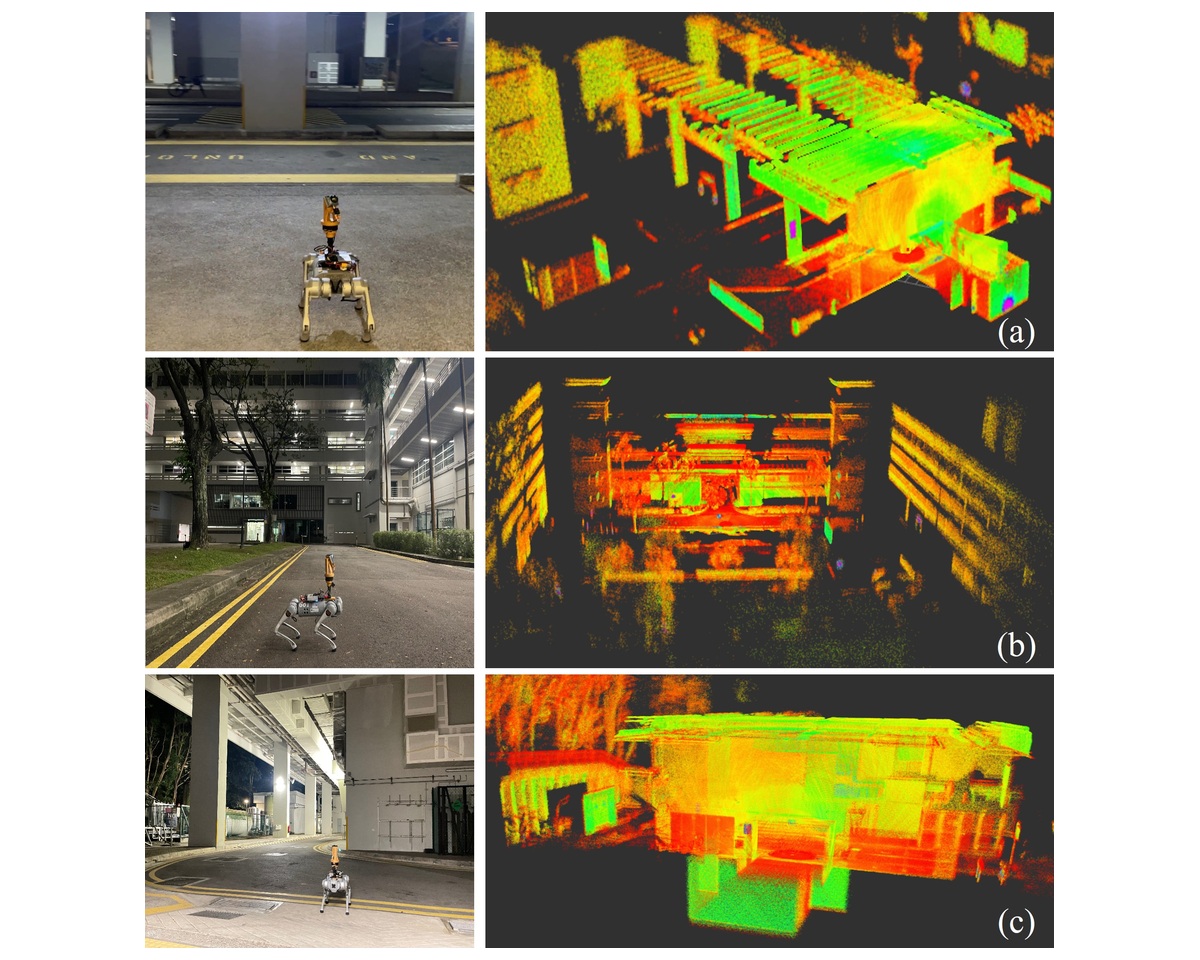
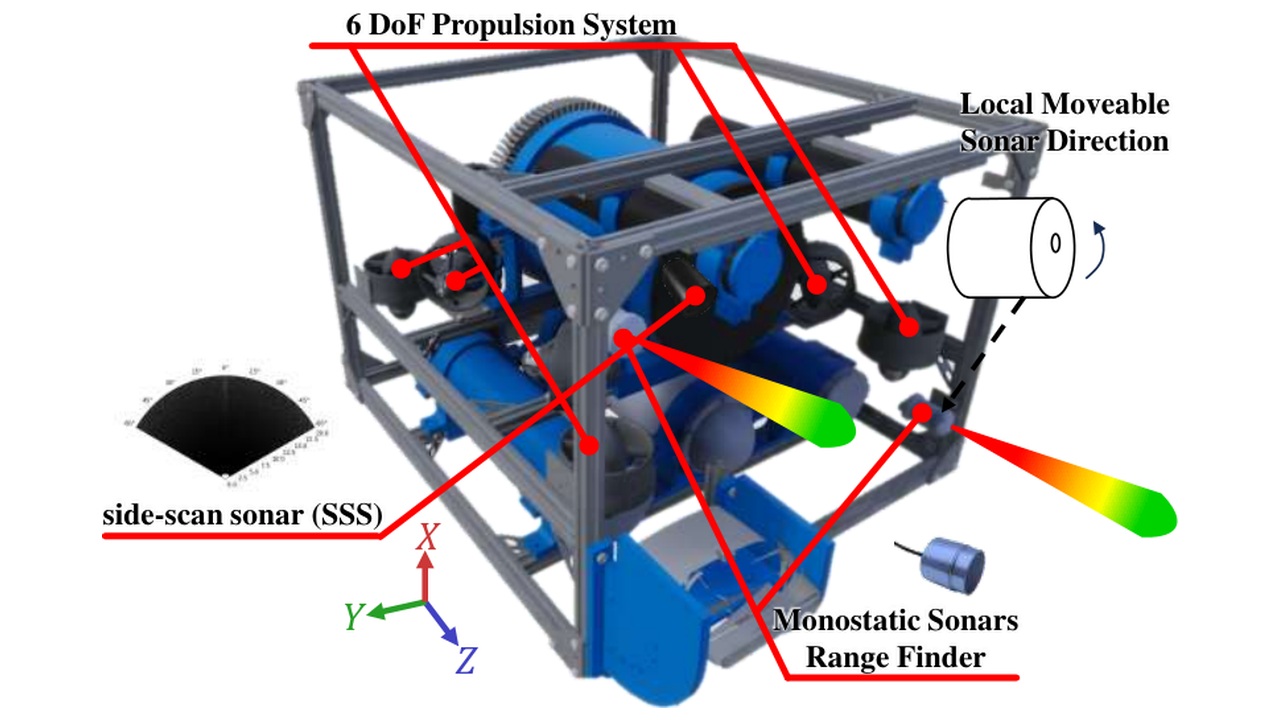

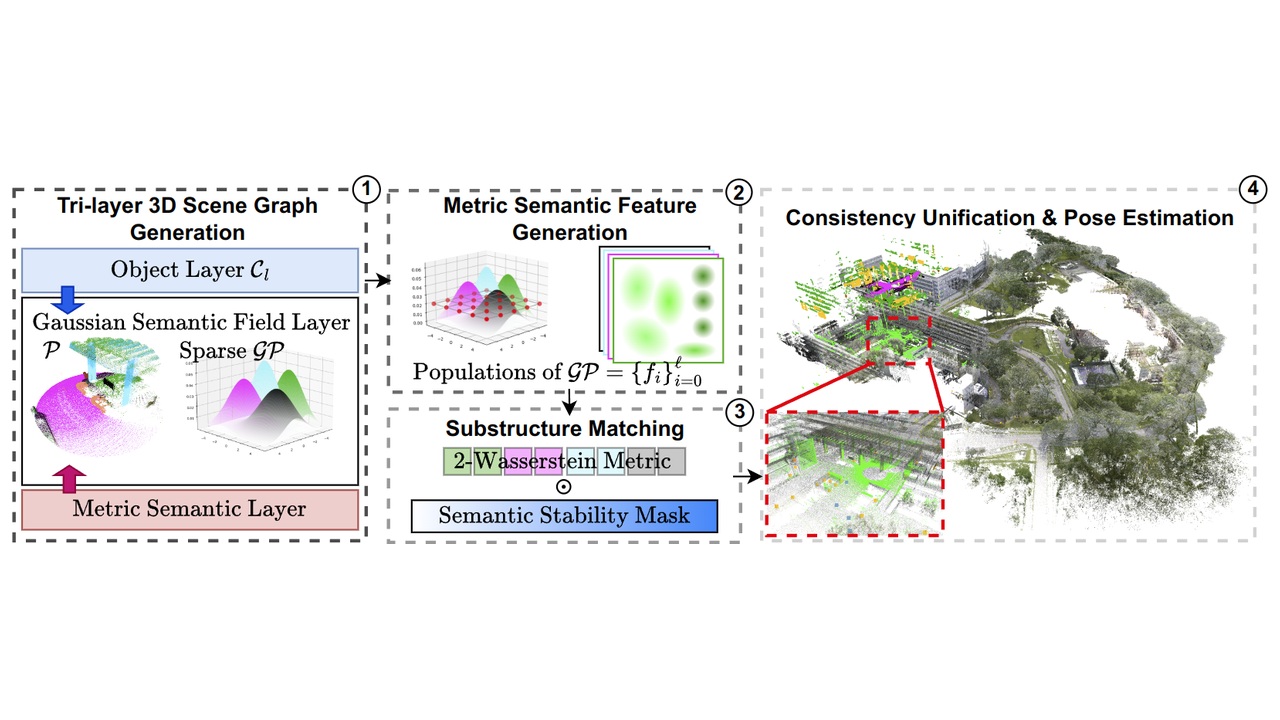
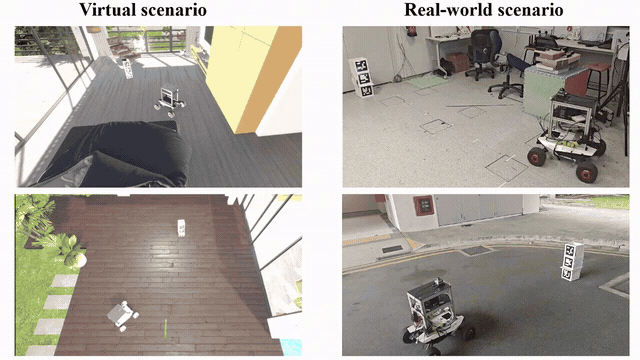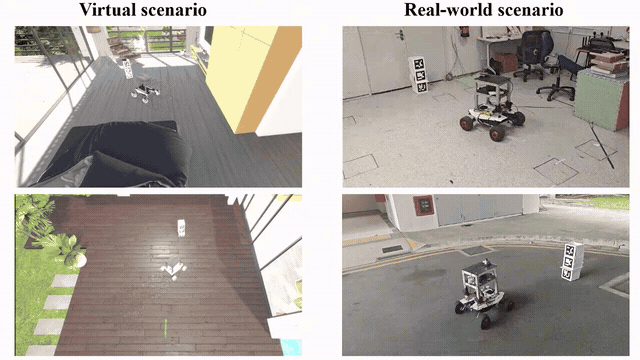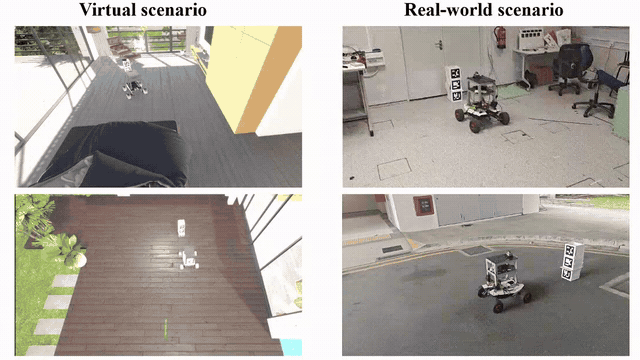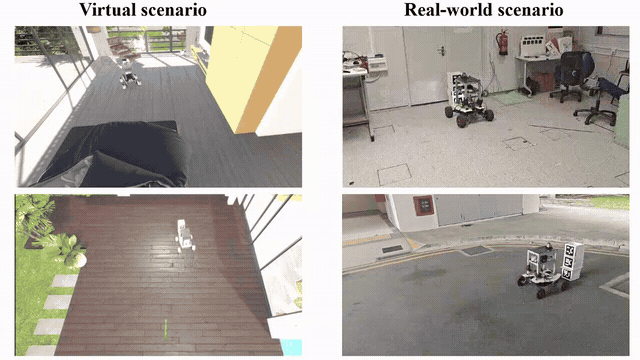
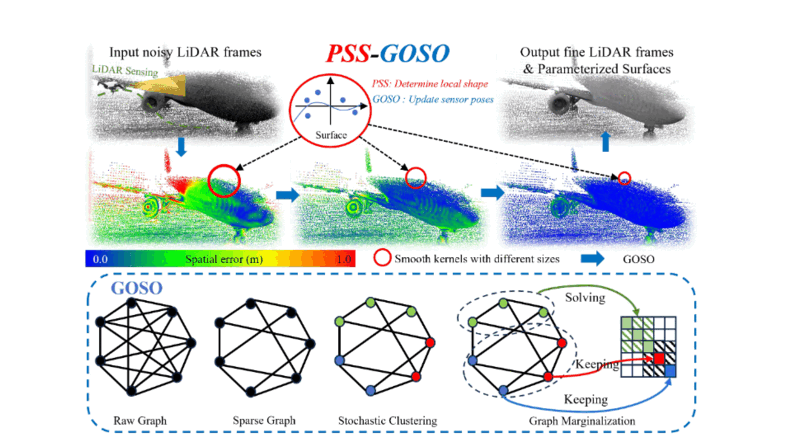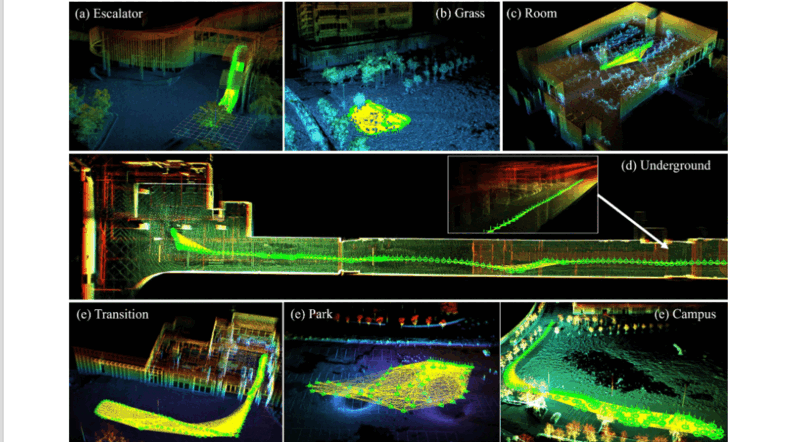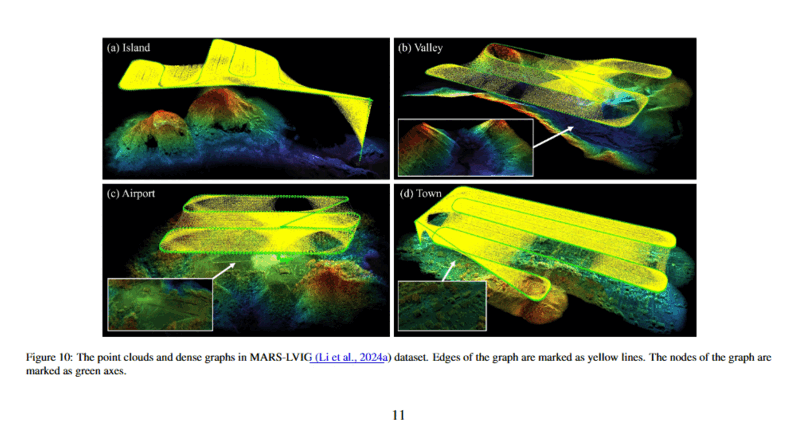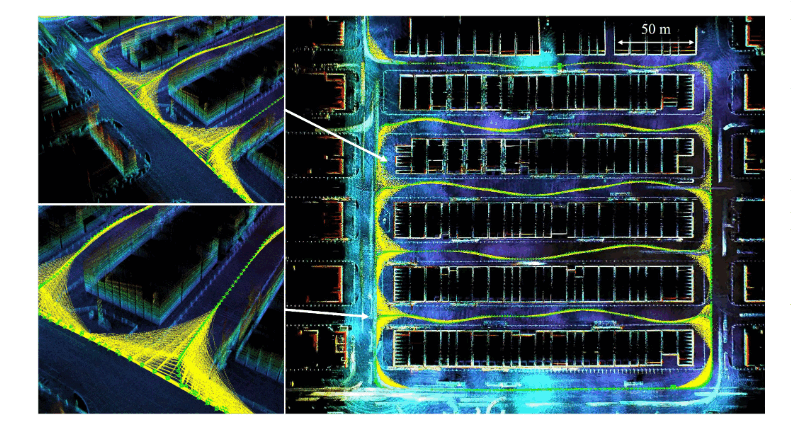
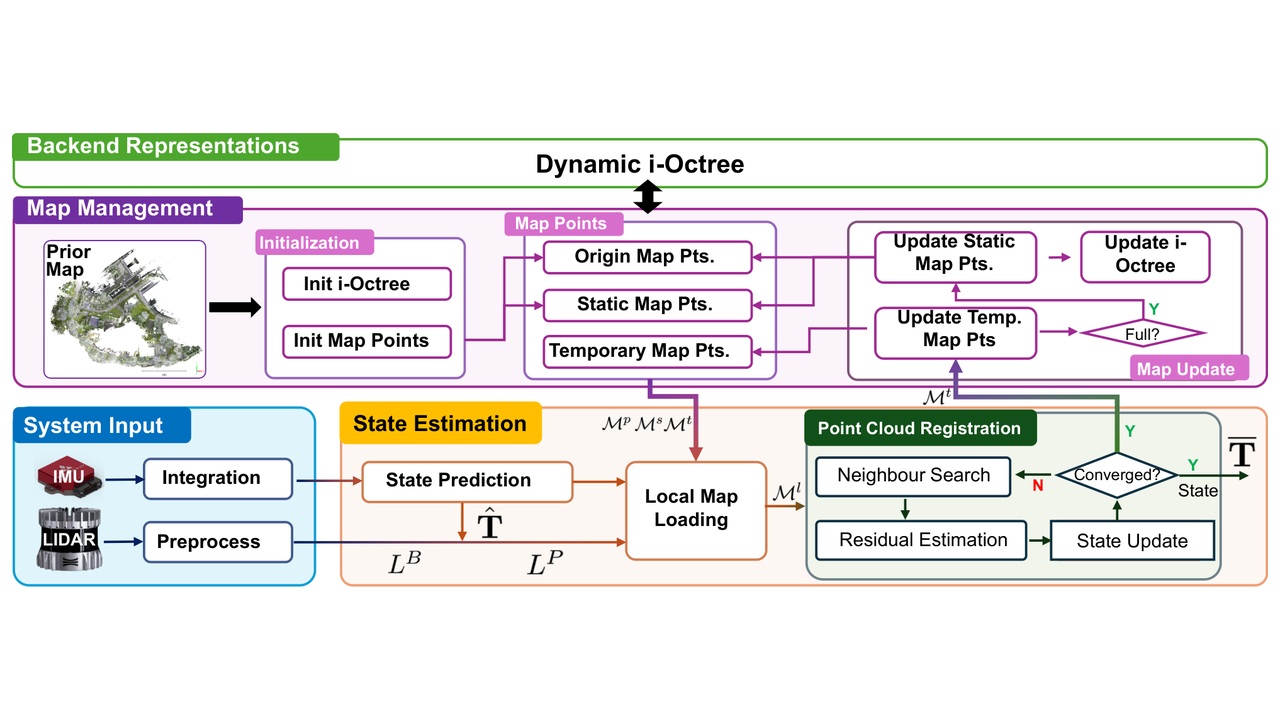
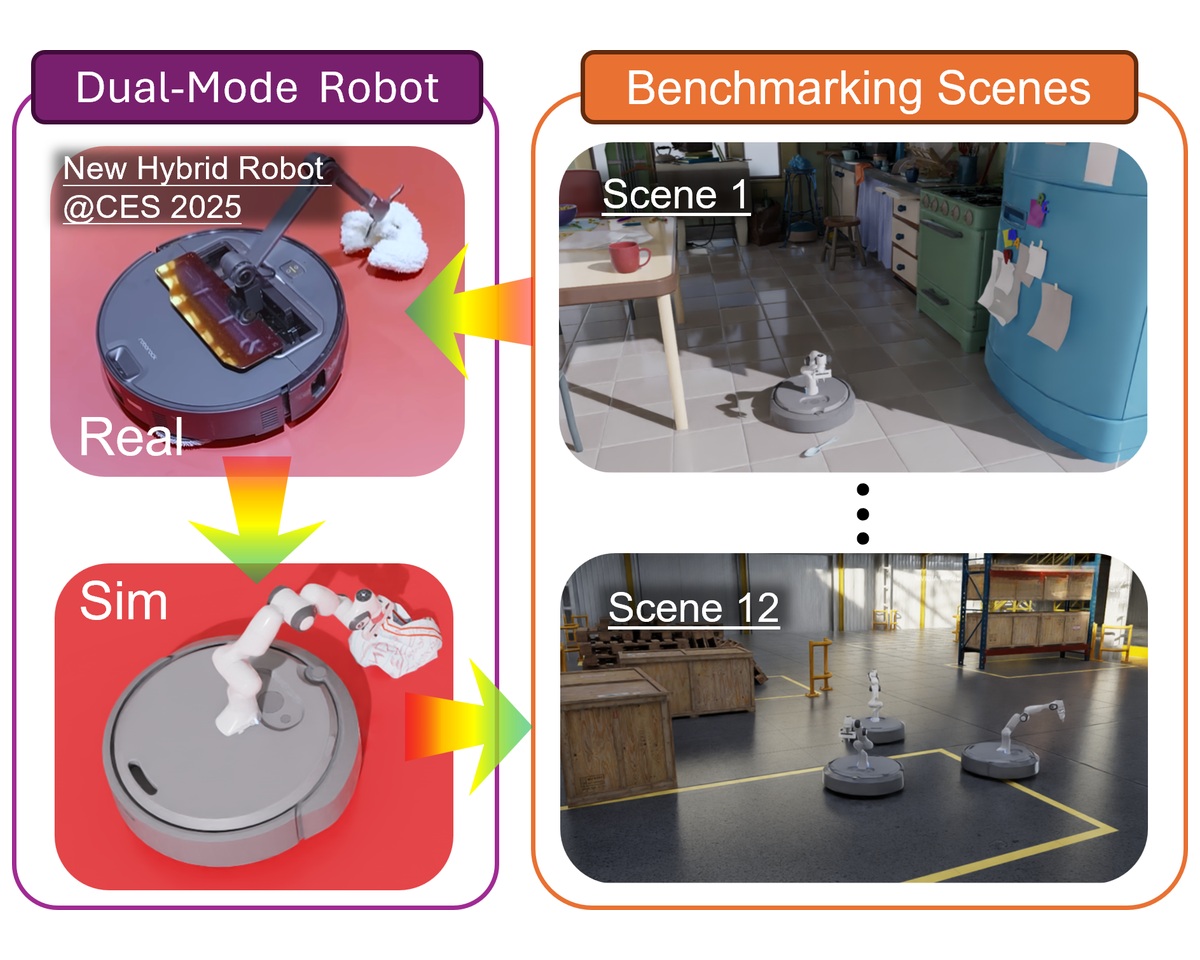
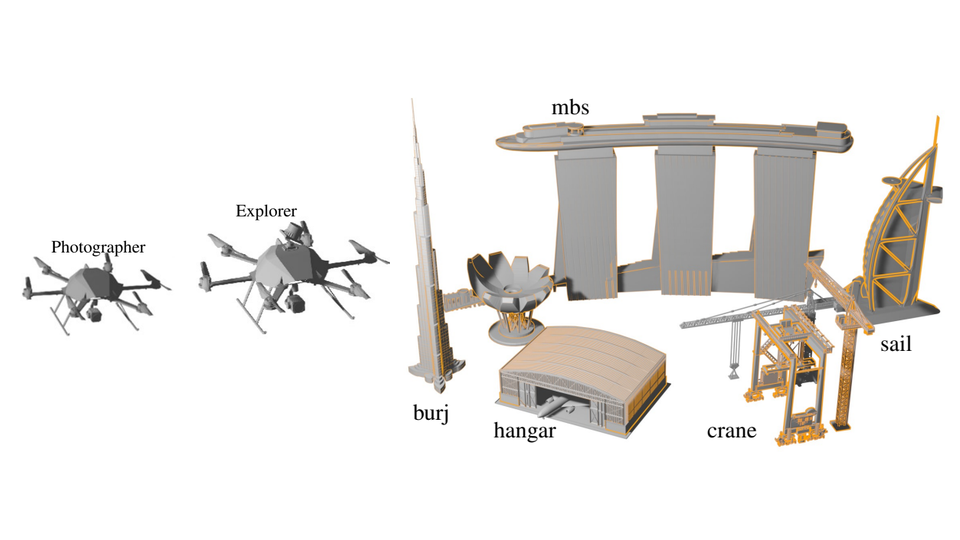
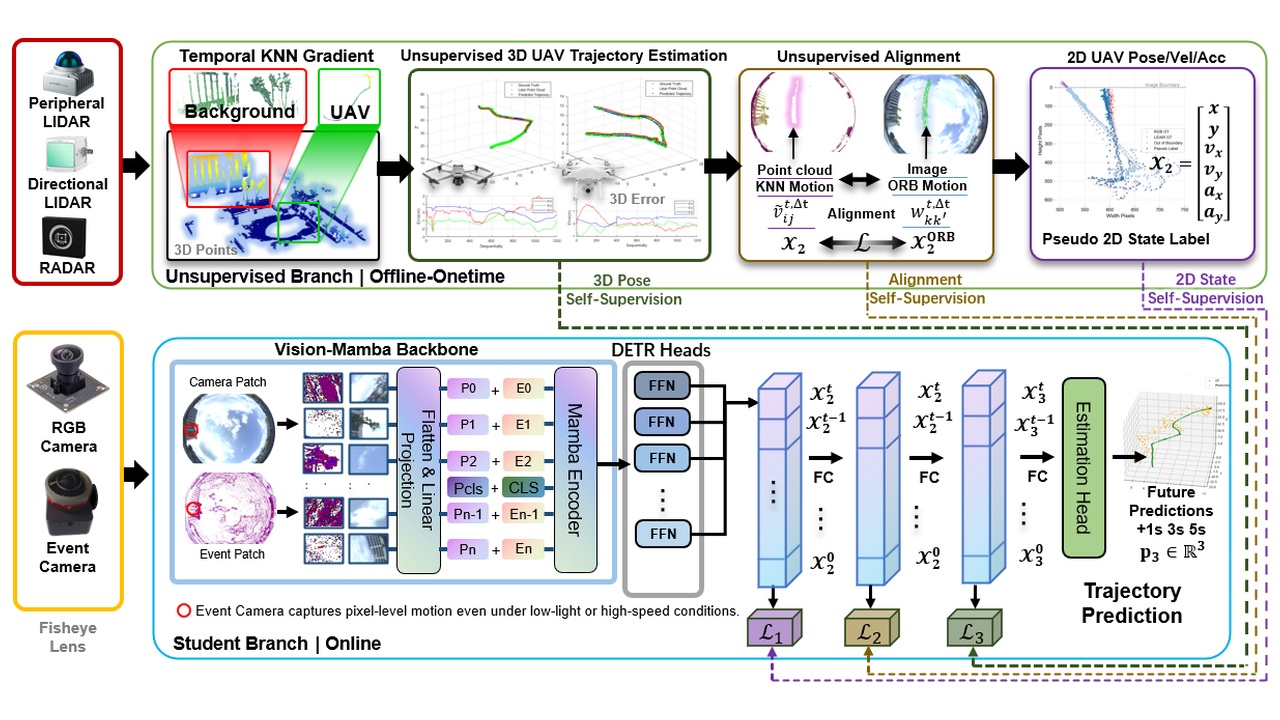
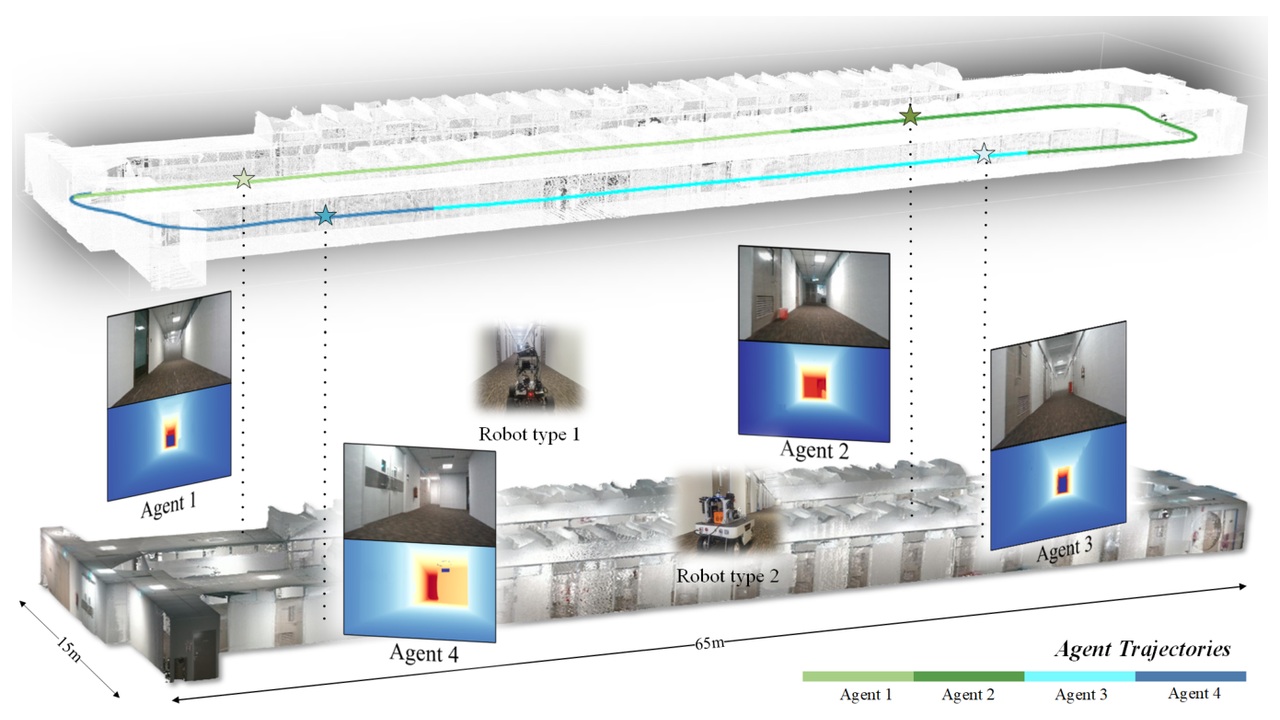
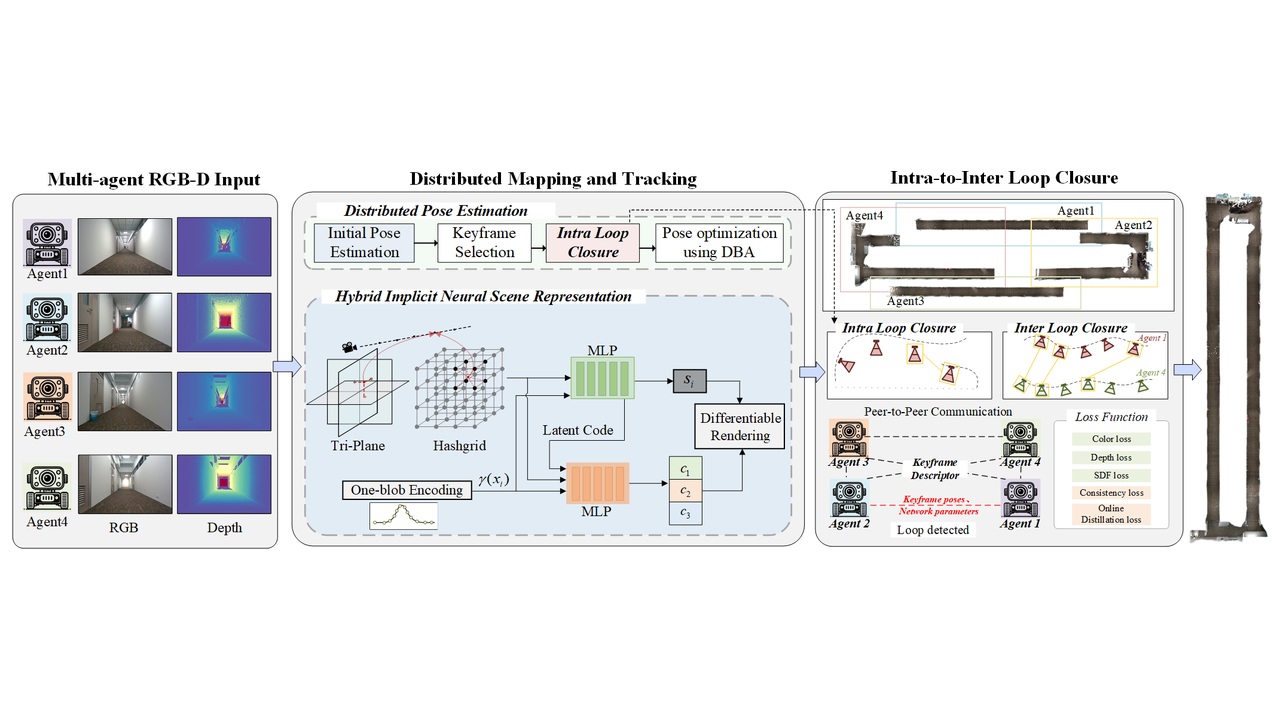
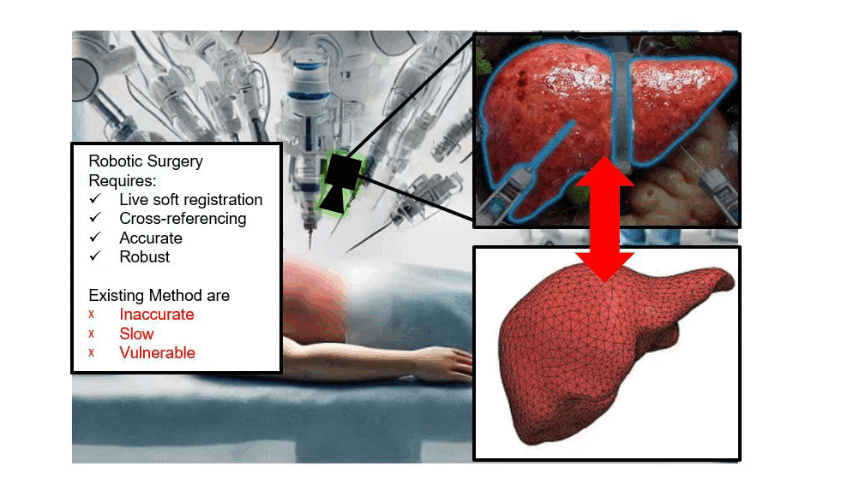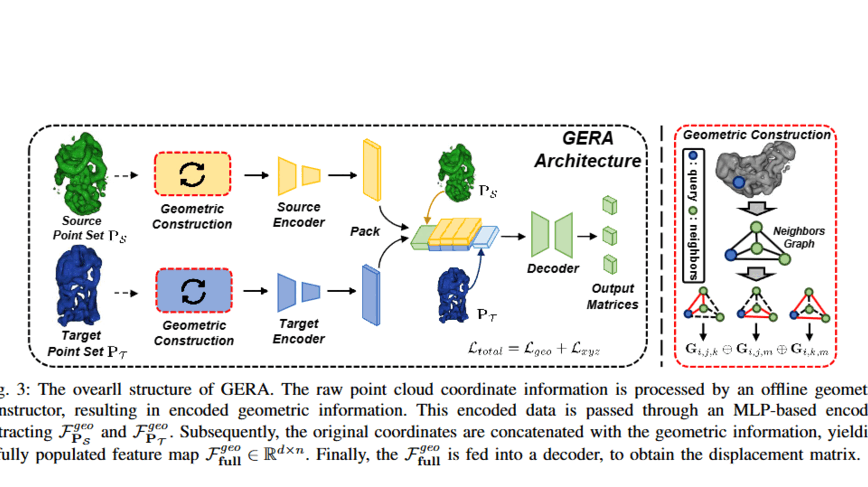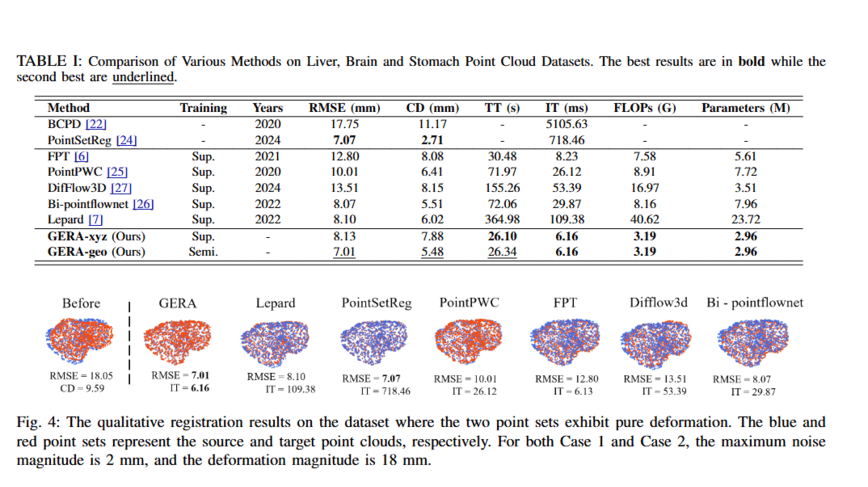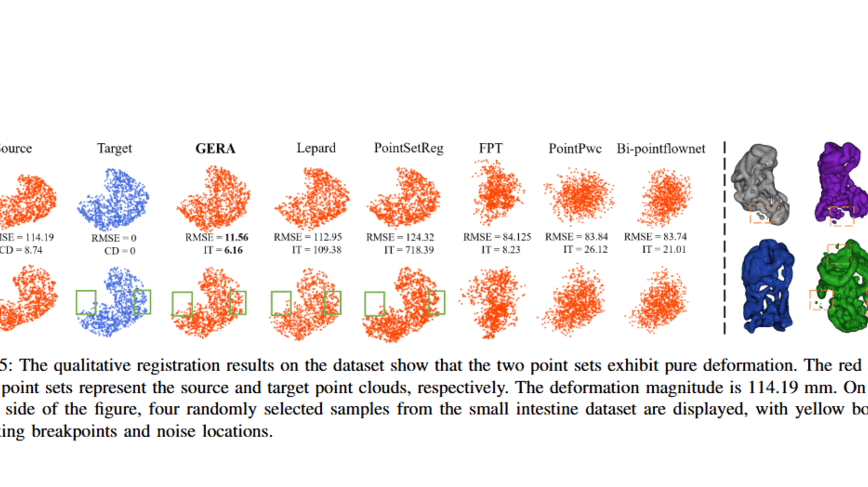
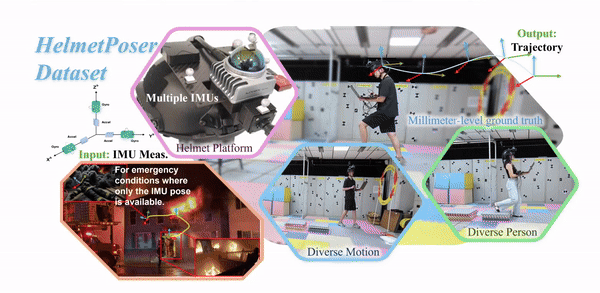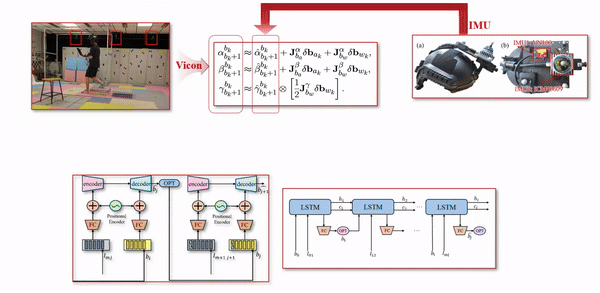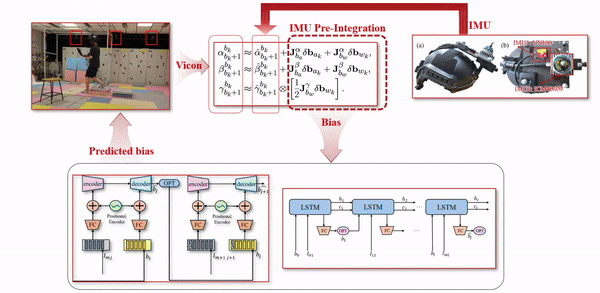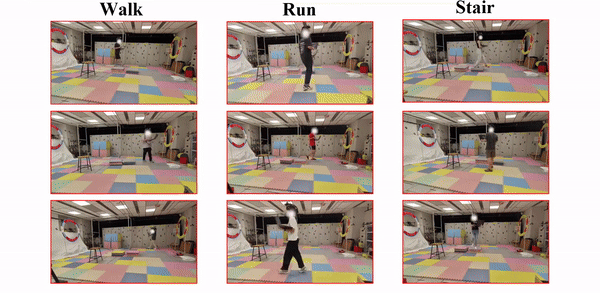
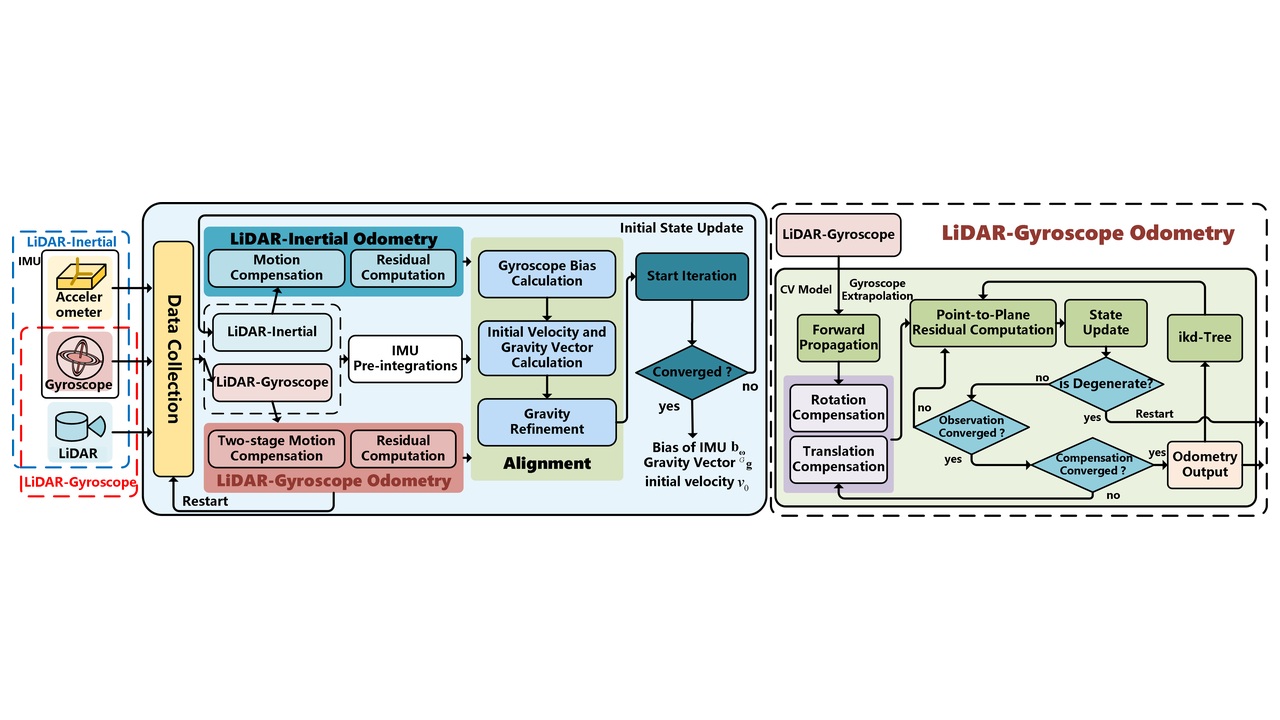
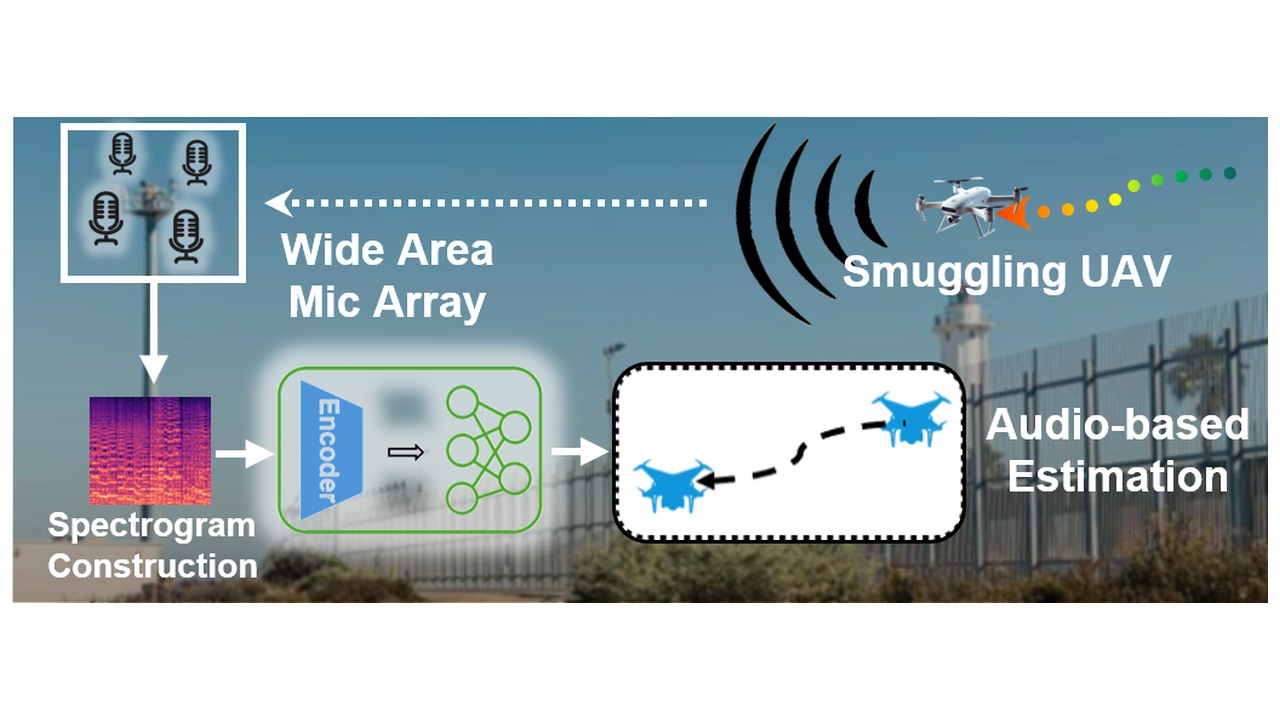
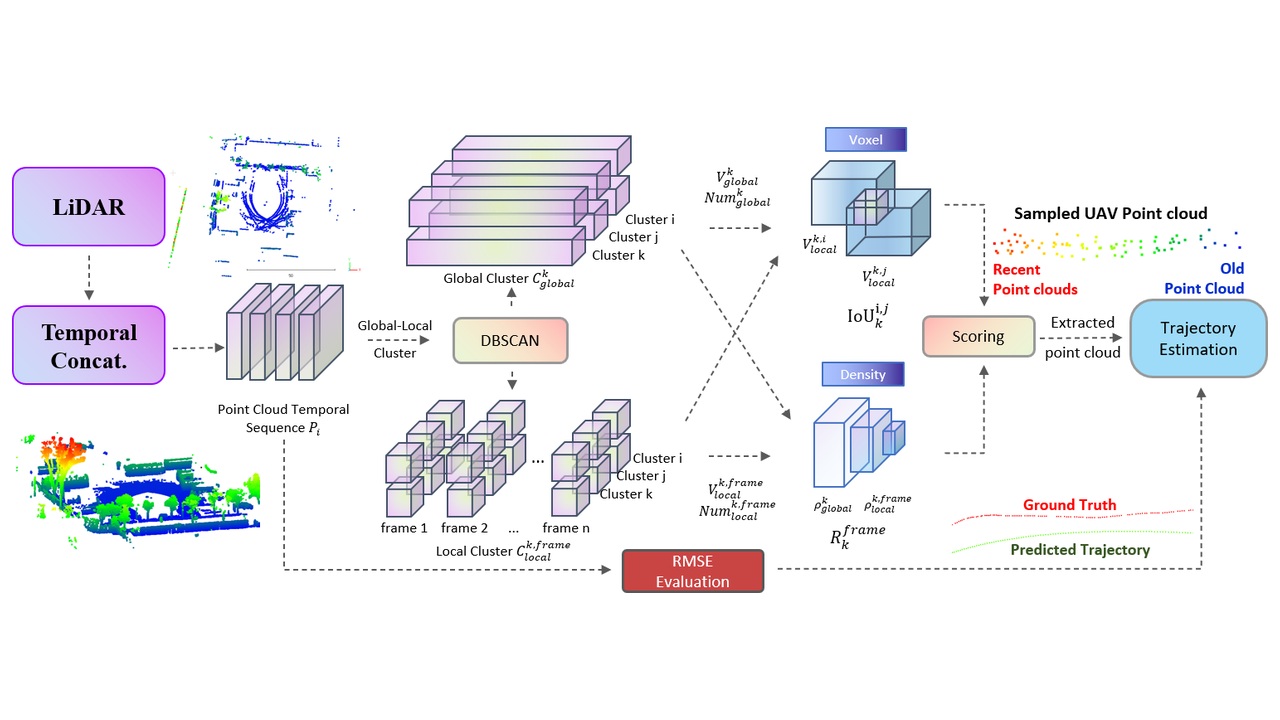
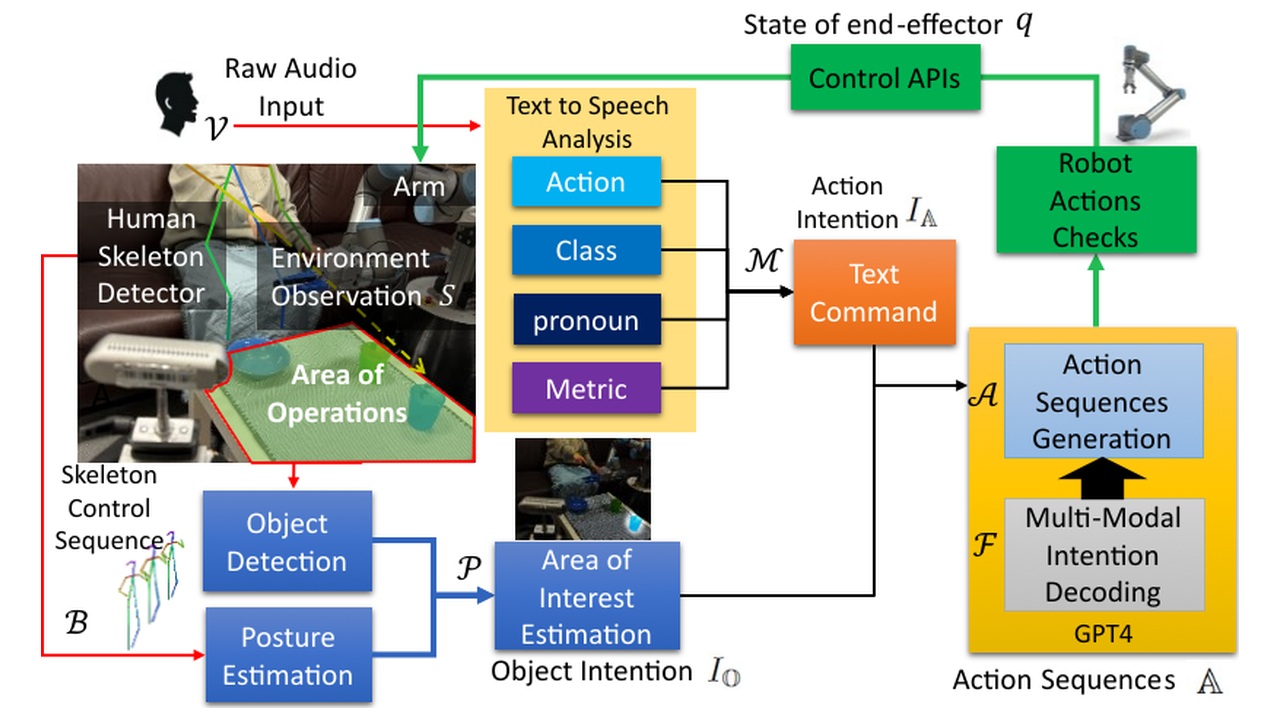
2024


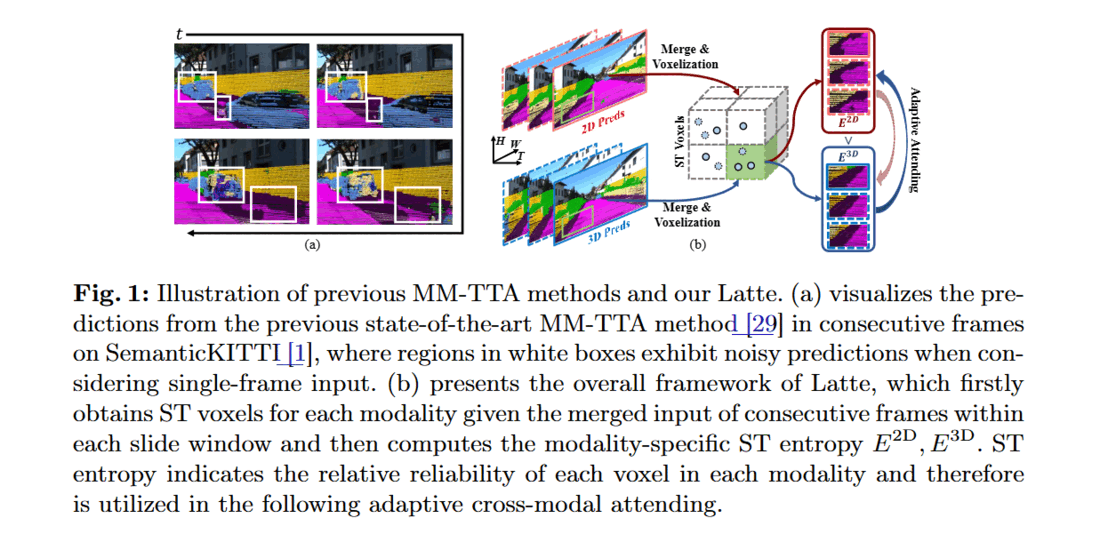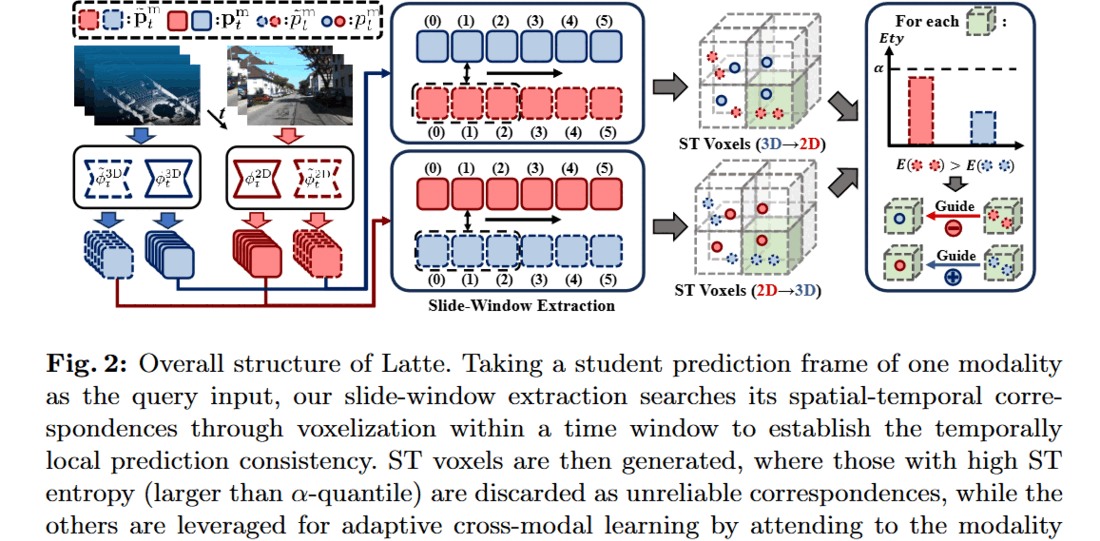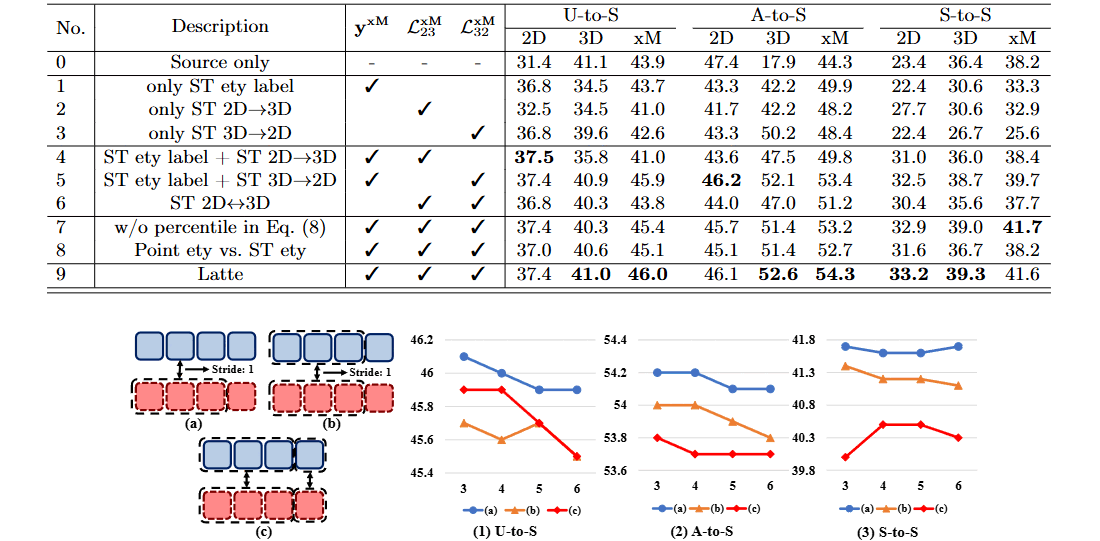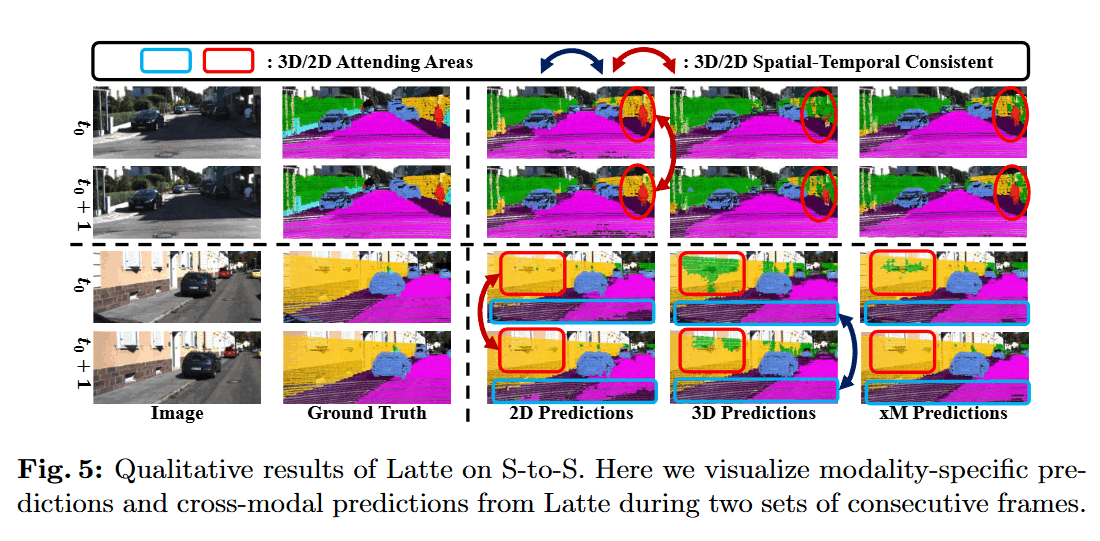
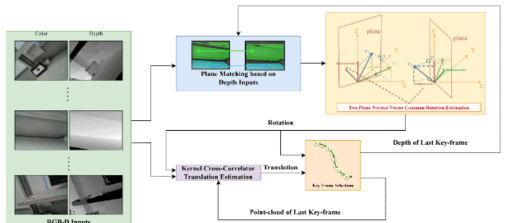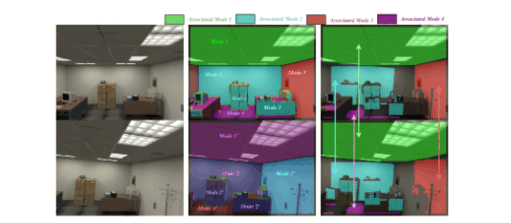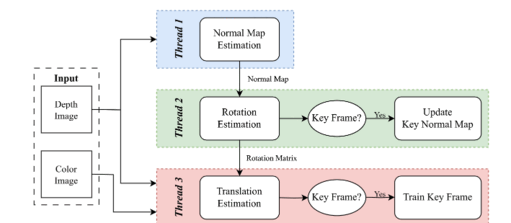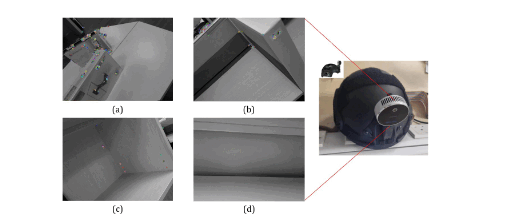




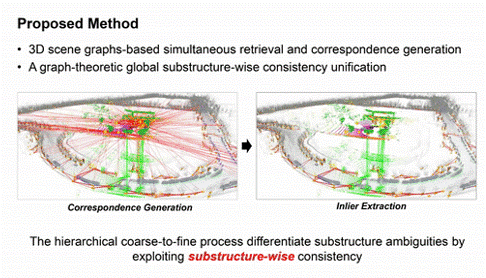
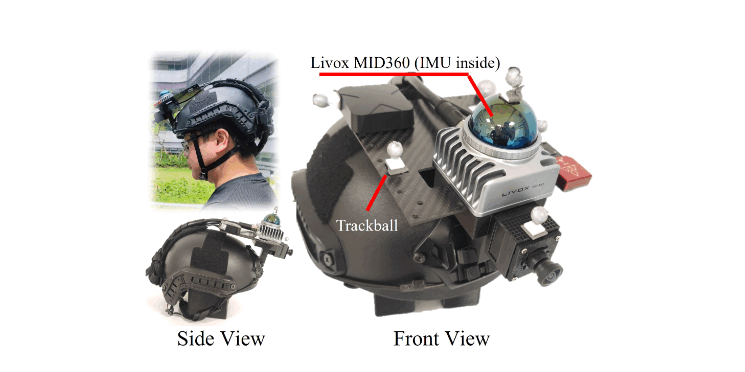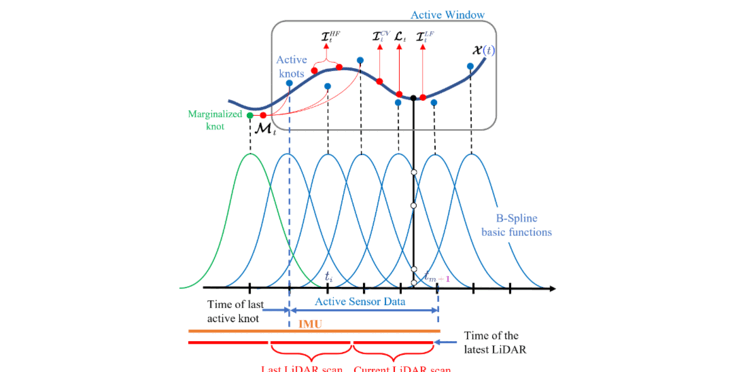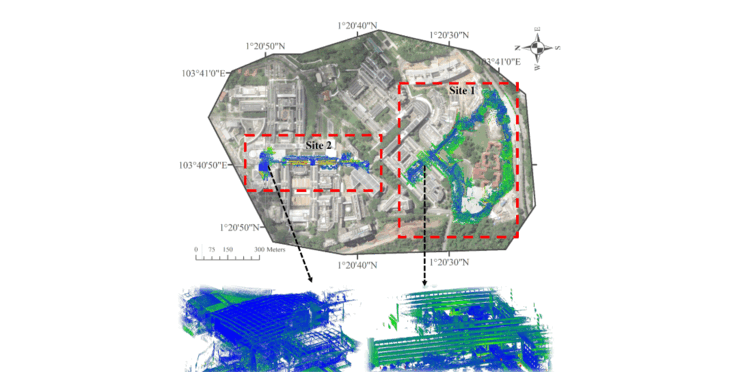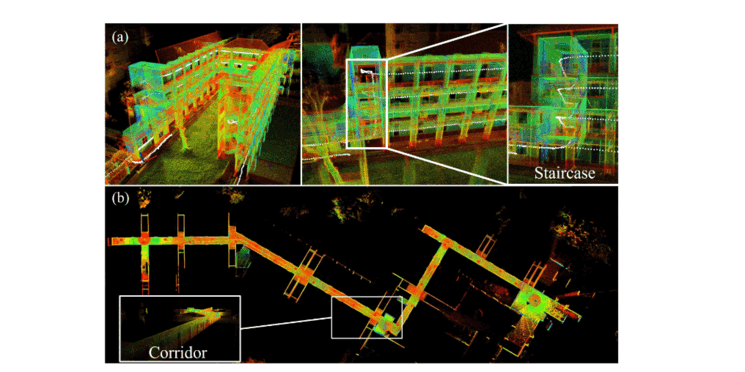


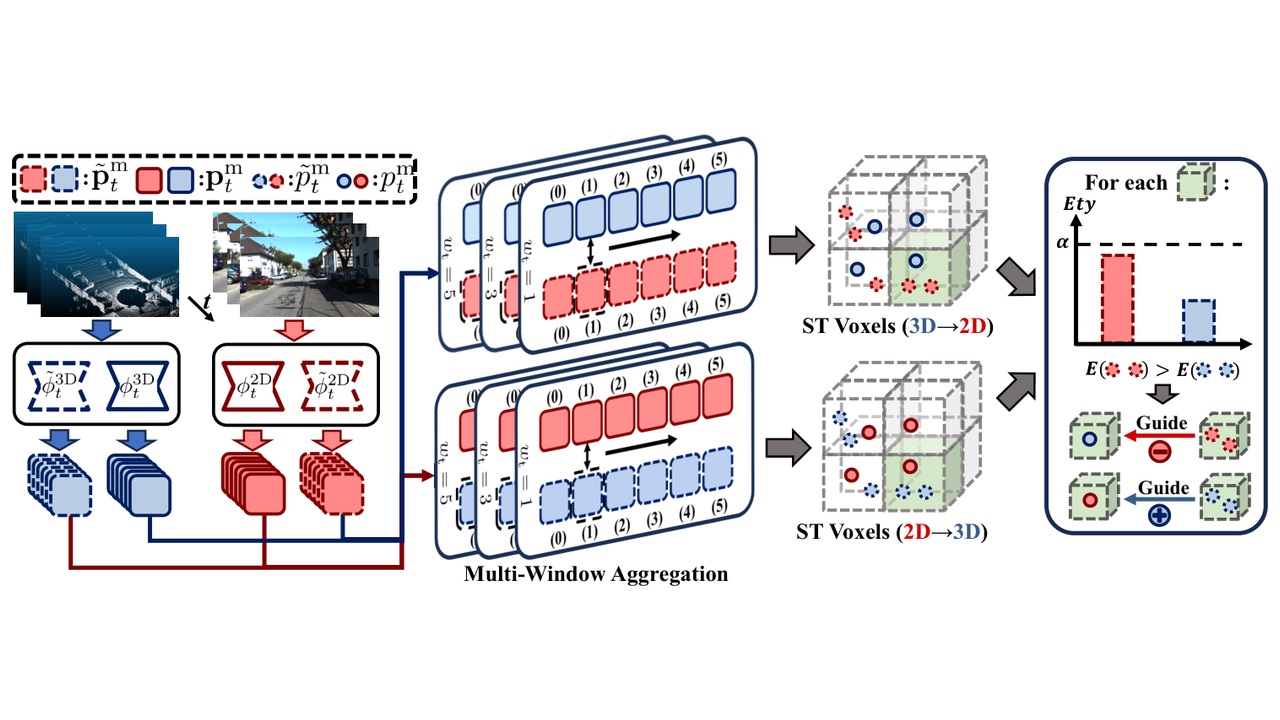

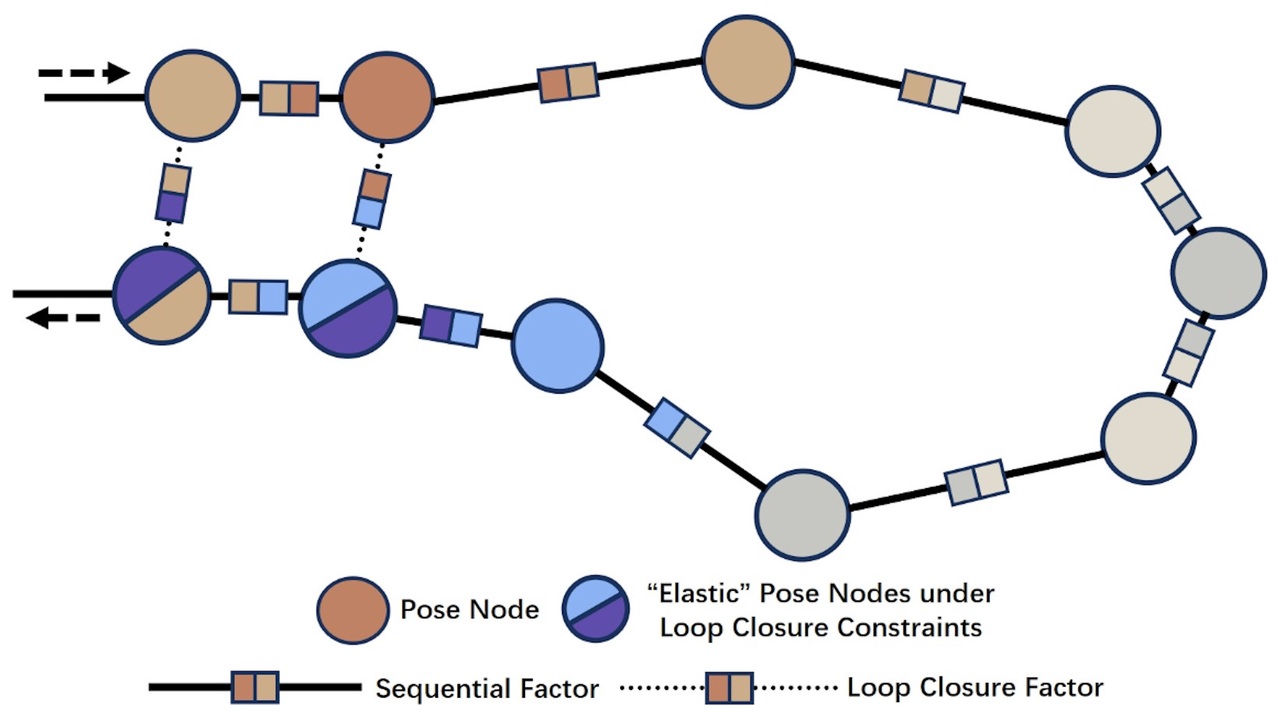
2023
-
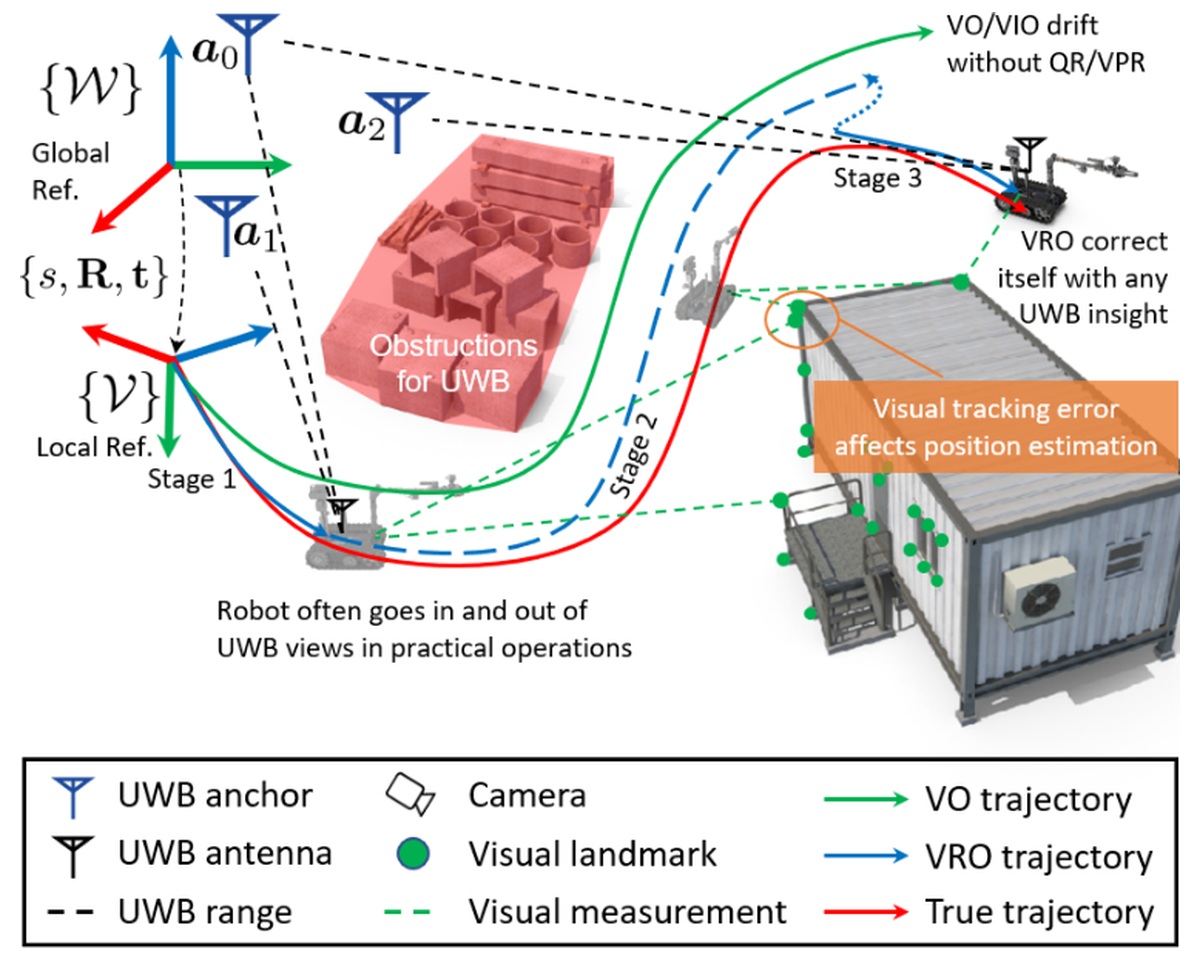 VR-SLAM: A Visual-Range Simultaneous Localization and Mapping System using Monocular Camera and Ultra-wideband SensorsarXiv preprint arXiv:2303.10903, 2023
- Unmanned aerial vehicle and localization method for unmanned aerial vehicle2023US Patent App. 18/040,148
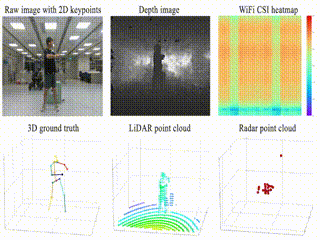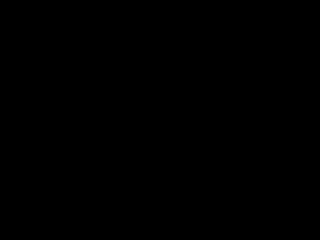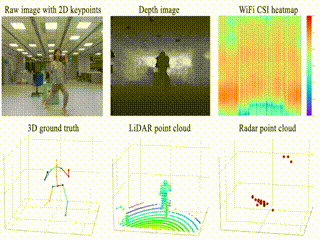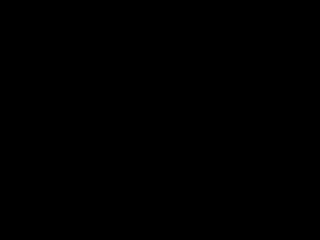
2022
2021
-
-
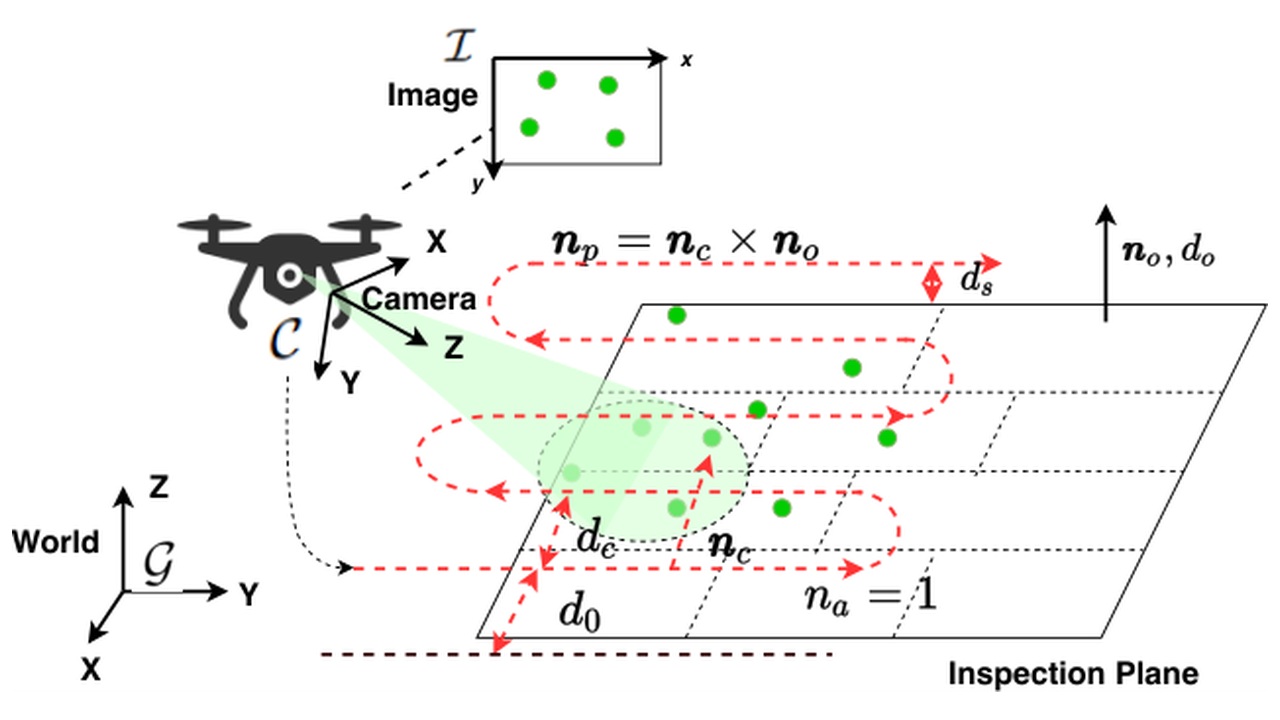
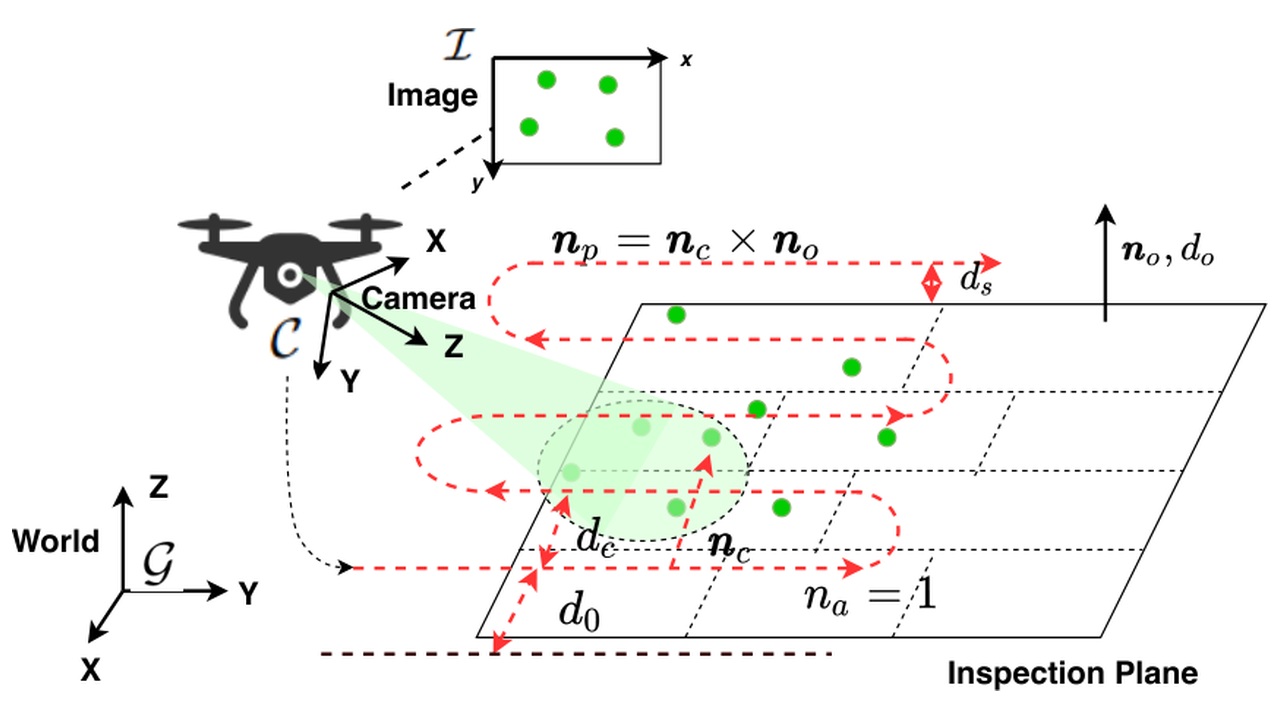 Vision based autonomous UAV plane estimation and following for building inspectionarXiv preprint arXiv:2102.01423, 2021
2020
2019
2018
-
-
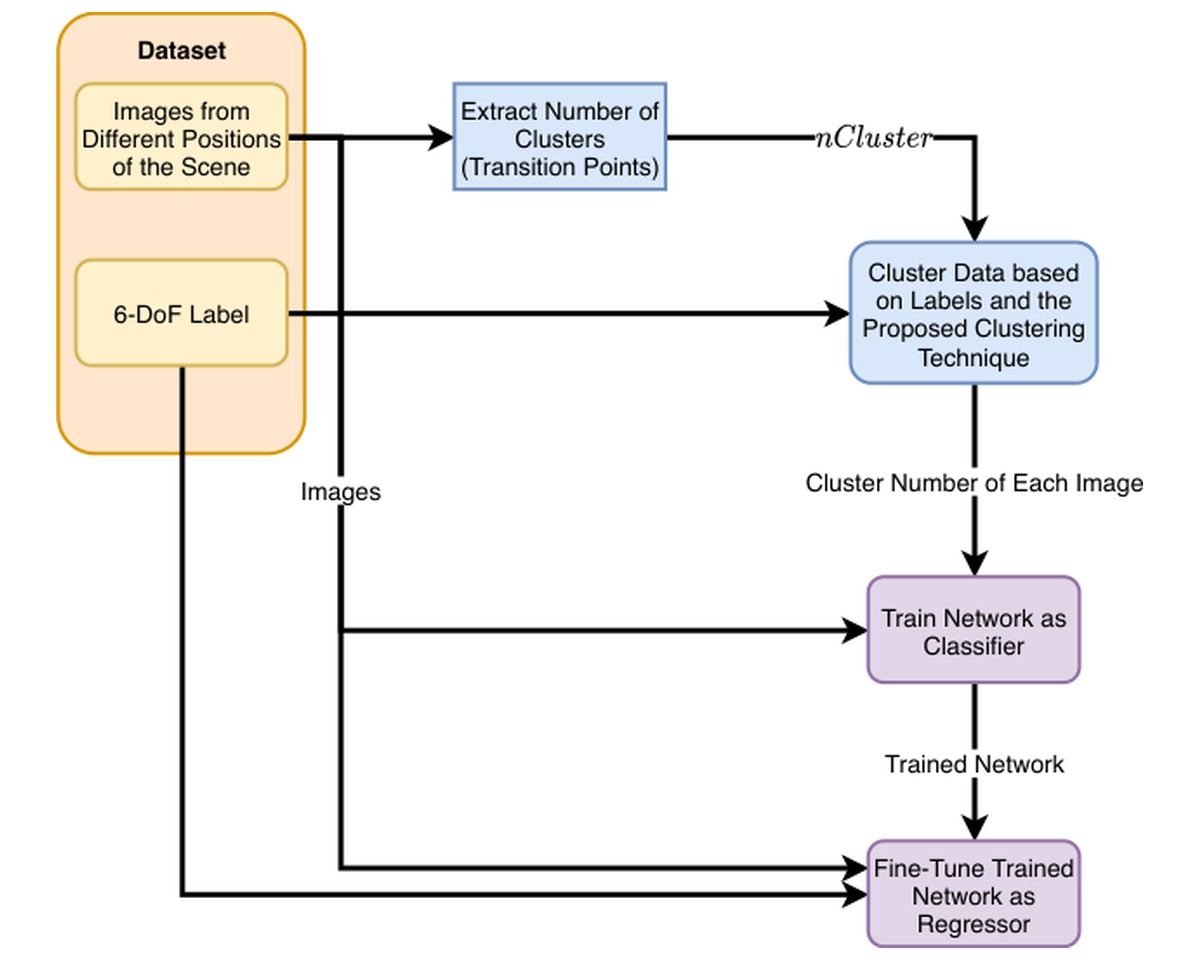 A new approach to train convolutional neural networks for real-time 6-DOF camera relocalizationIn IEEE International Conference on Control and Automation (ICCA), 2018
2017
- Heterogeneous stereo: A human vision inspired method for general robotics sensingIn IEEE Region 10 Conference (TENCON), 2017
2015
- An Automatic Self-Calibration Approach for Wide Baseline Stereo Cameras Using Sea Surface ImagesUnmanned Systems (US), 2015
- Vision based long range object detection and tracking for unmanned surface vehicleIn IEEE International Conference on Cybernetics and Intelligent Systems (CIS) and IEEE Conference on Robotics, Automation and Mechatronics (RAM), 2015
2014
2013
- Development control and navigation of OctocopterIn IEEE International Conference on Control and Automation (ICCA), 2013